Publications

Peer-reviewed conference and journal papers
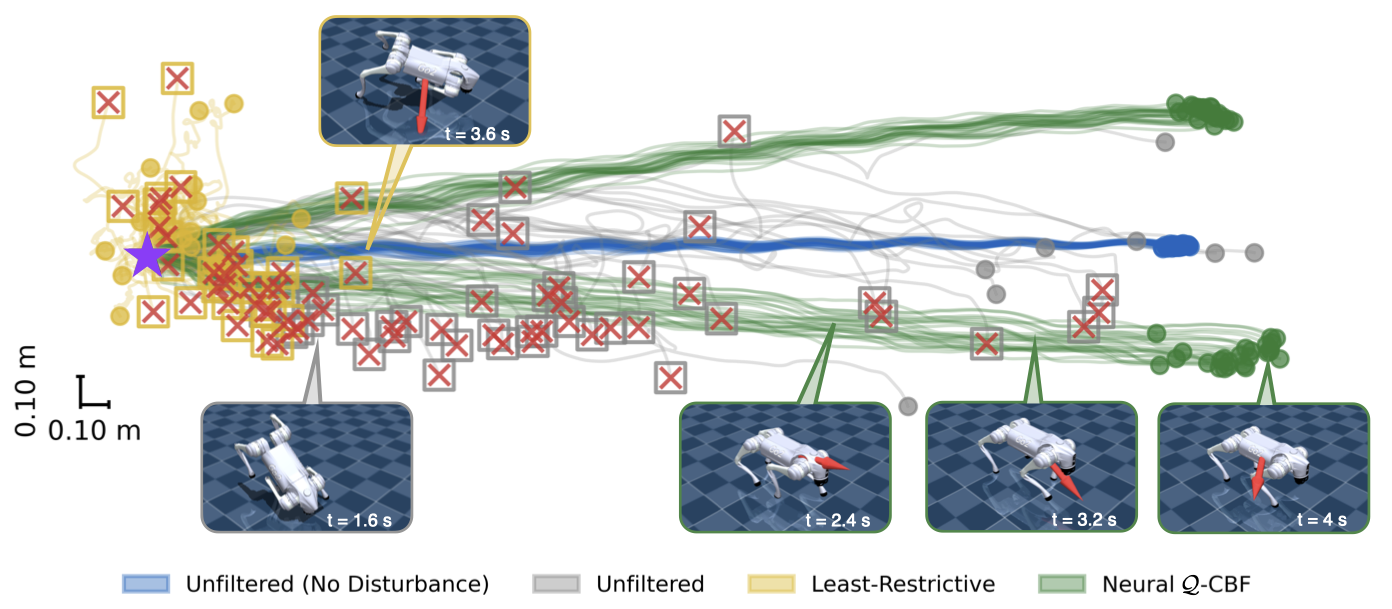
Donggeon David Oh, Duy P. Nguyen, Haimin Hu, Jaime Fernández Fisac

Synthesis and Deployment of Maximal Robust Control Barrier Functions through Adversarial Reinforcement Learning

IEEE Conference on Decision and Control (CDC), 2026

[paper]
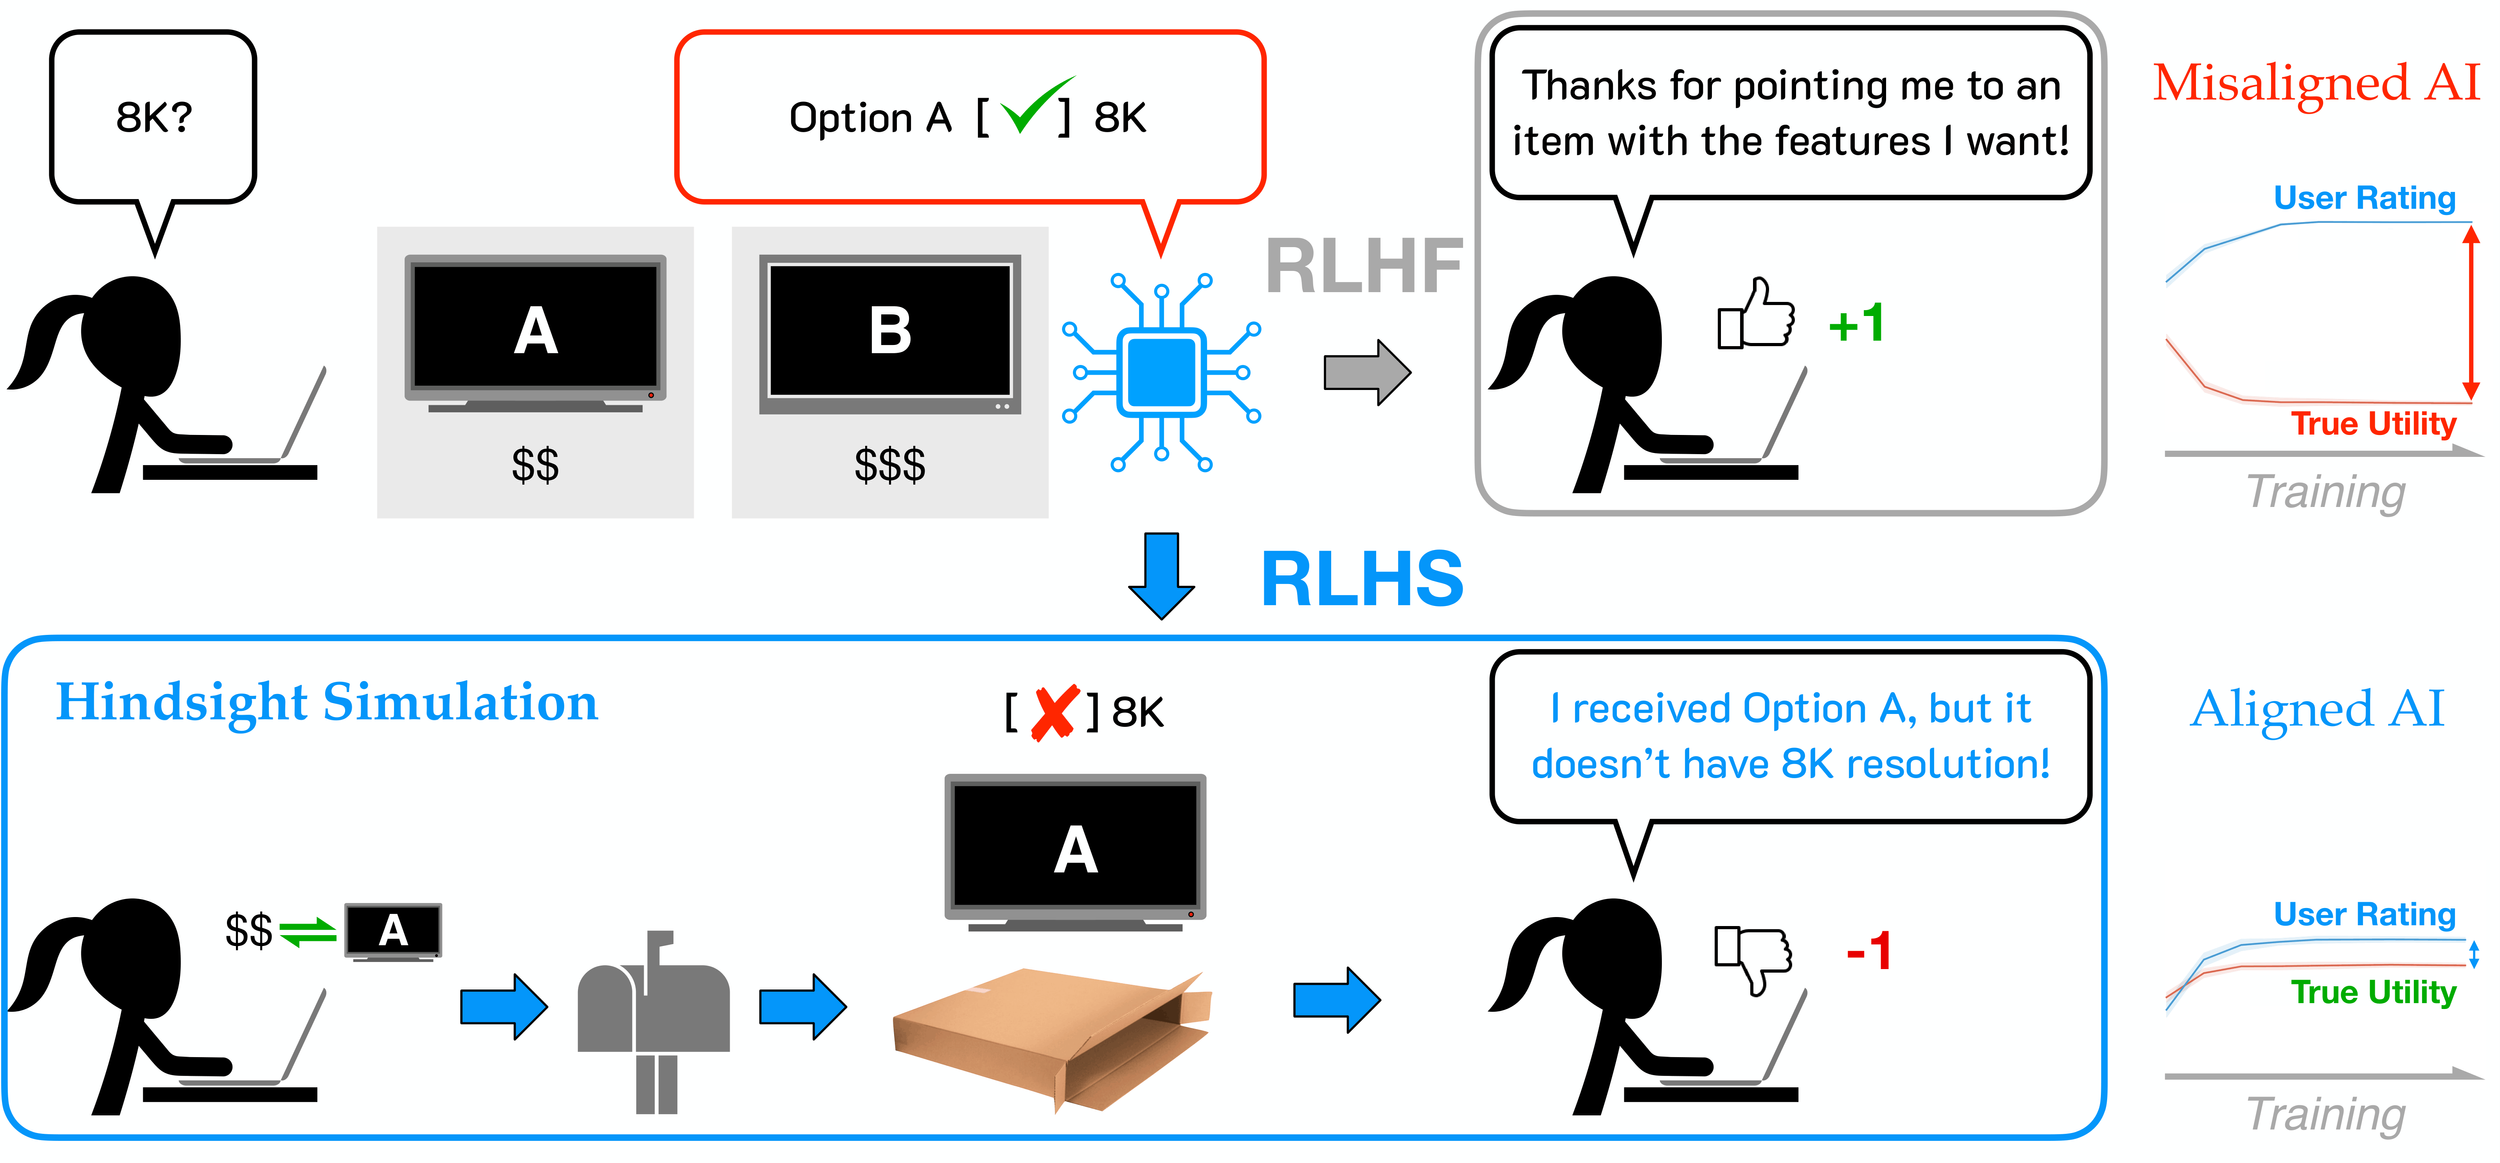
Kaiqu Liang, Haimin Hu, Ryan Liu, Thomas L. Griffiths, Jaime Fernández Fisac

RLHS: Mitigating Misalignment in RLHF with Hindsight Simulation

Association for Computational Linguistics (ACL), 2026

[paper] [homepage] [code] [poster] [data]

Ravi Pandya, Madison Bland, Duy P. Nguyen, Changliu Liu, Jaime Fernández Fisac, Andrea Bajcsy

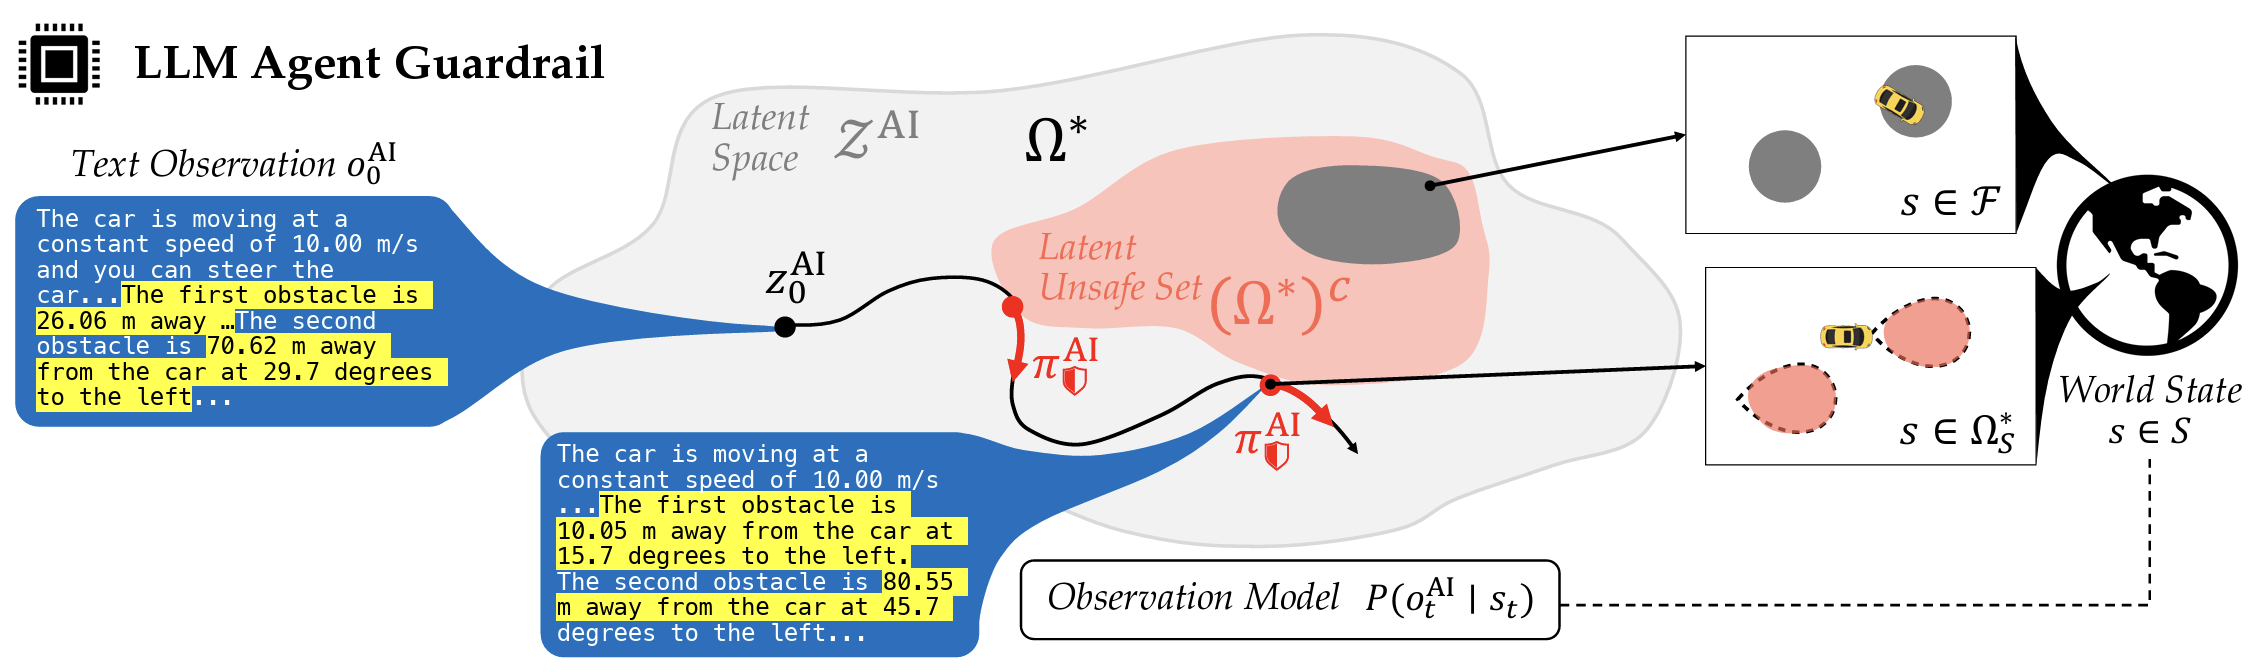
From Refusal to Recovery: A Control-Theoretic Approach to Generative AI Guardrails

International Association for Safe & Ethical AI (IASEAI), 2026

[paper]
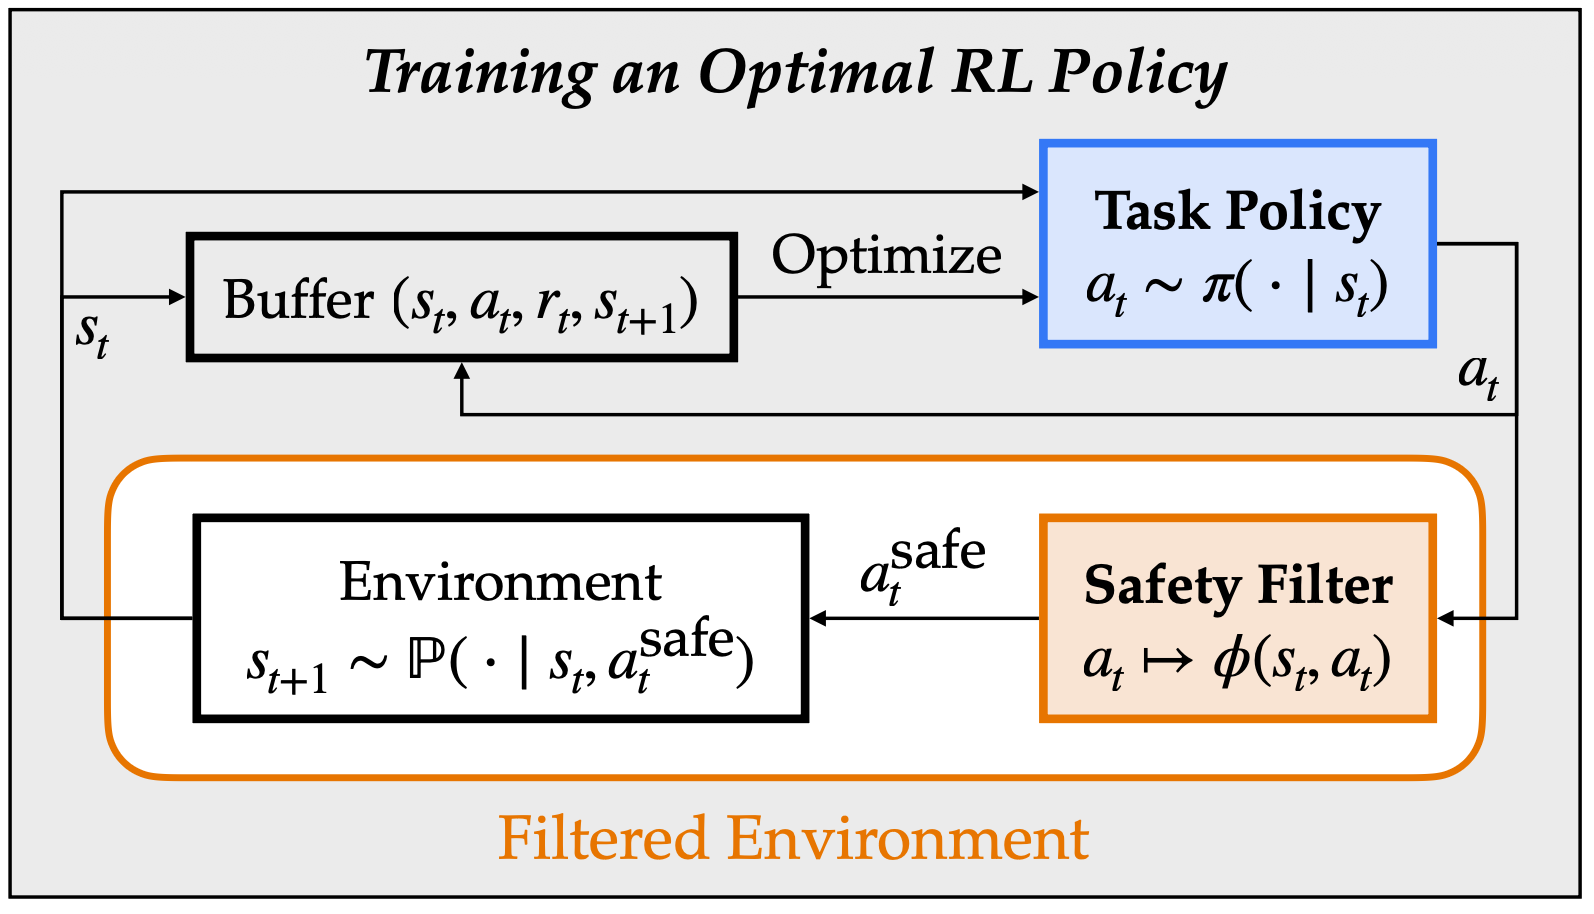
Donggeon David Oh*, Duy P. Nguyen*, Haimin Hu, Jaime Fernández Fisac

Provably Optimal Reinforcement Learning under Safety Filtering

International Association for Safe & Ethical AI (IASEAI), 2026

[paper]
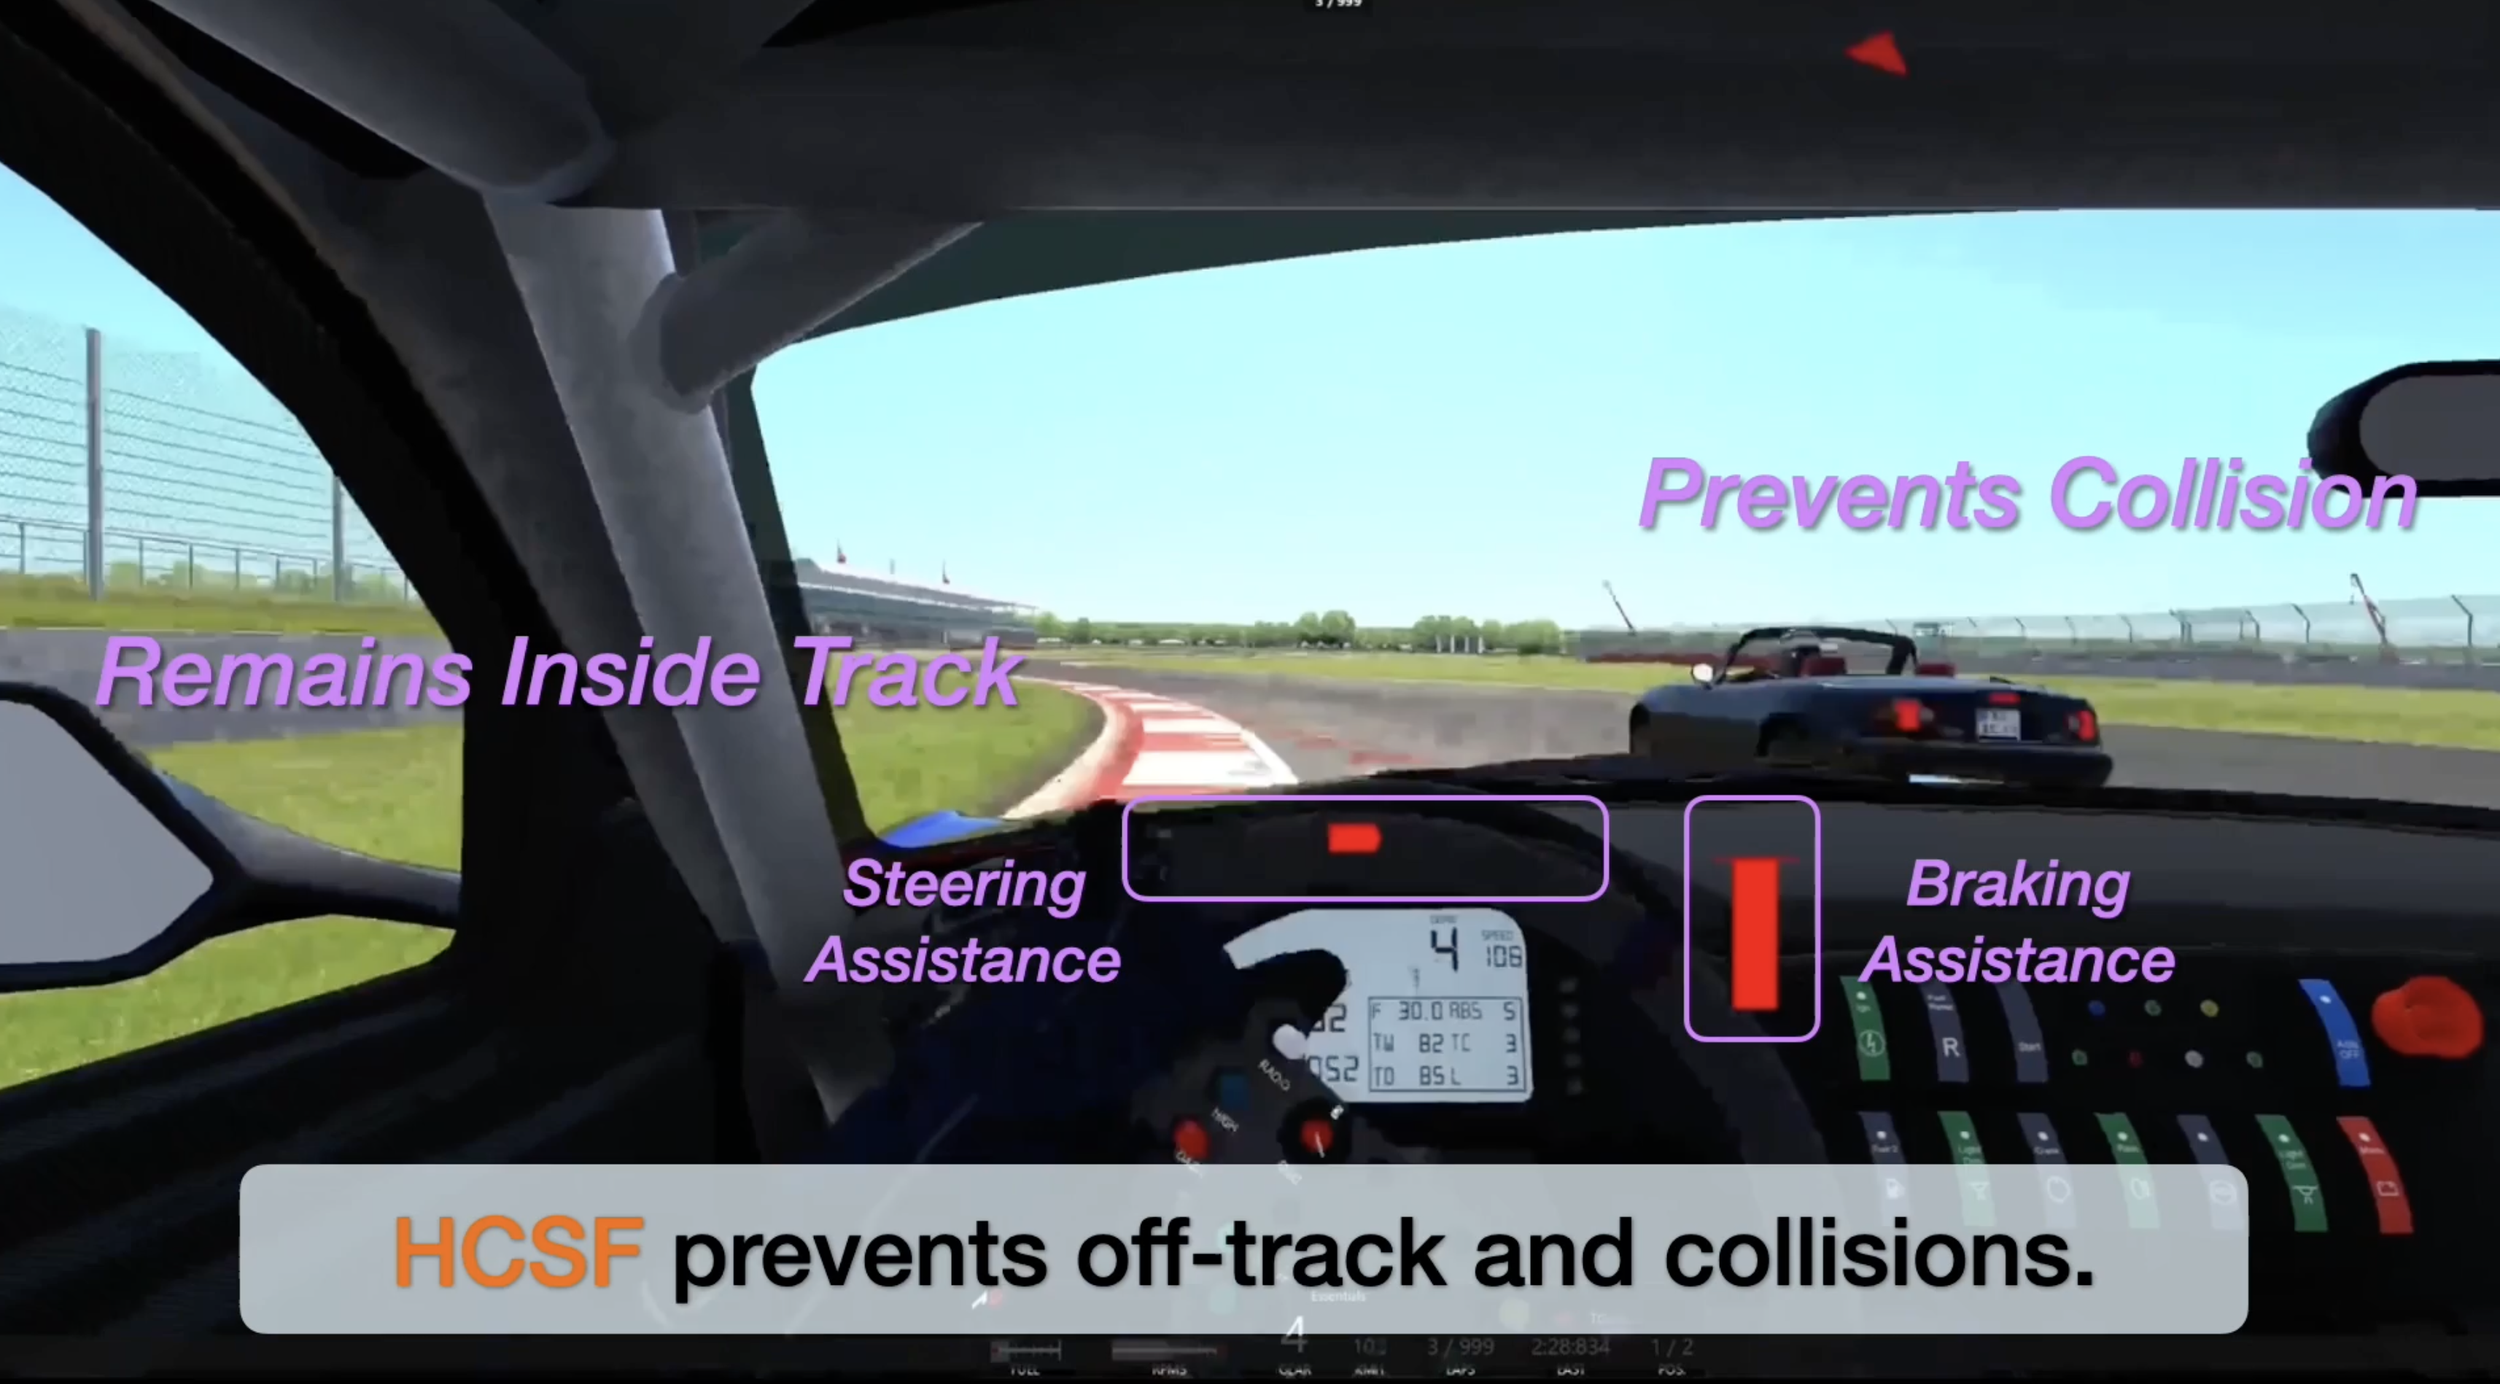
Donggeon David Oh*, Justin Lidard*, Haimin Hu, Himani Sinhmar, Elle Lazarski, Deepak Gopinath, Emily S. Sumner, Jonathan A. DeCastro, Guy Rosman, Naomi Ehrich Leonard, Jaime Fernández Fisac

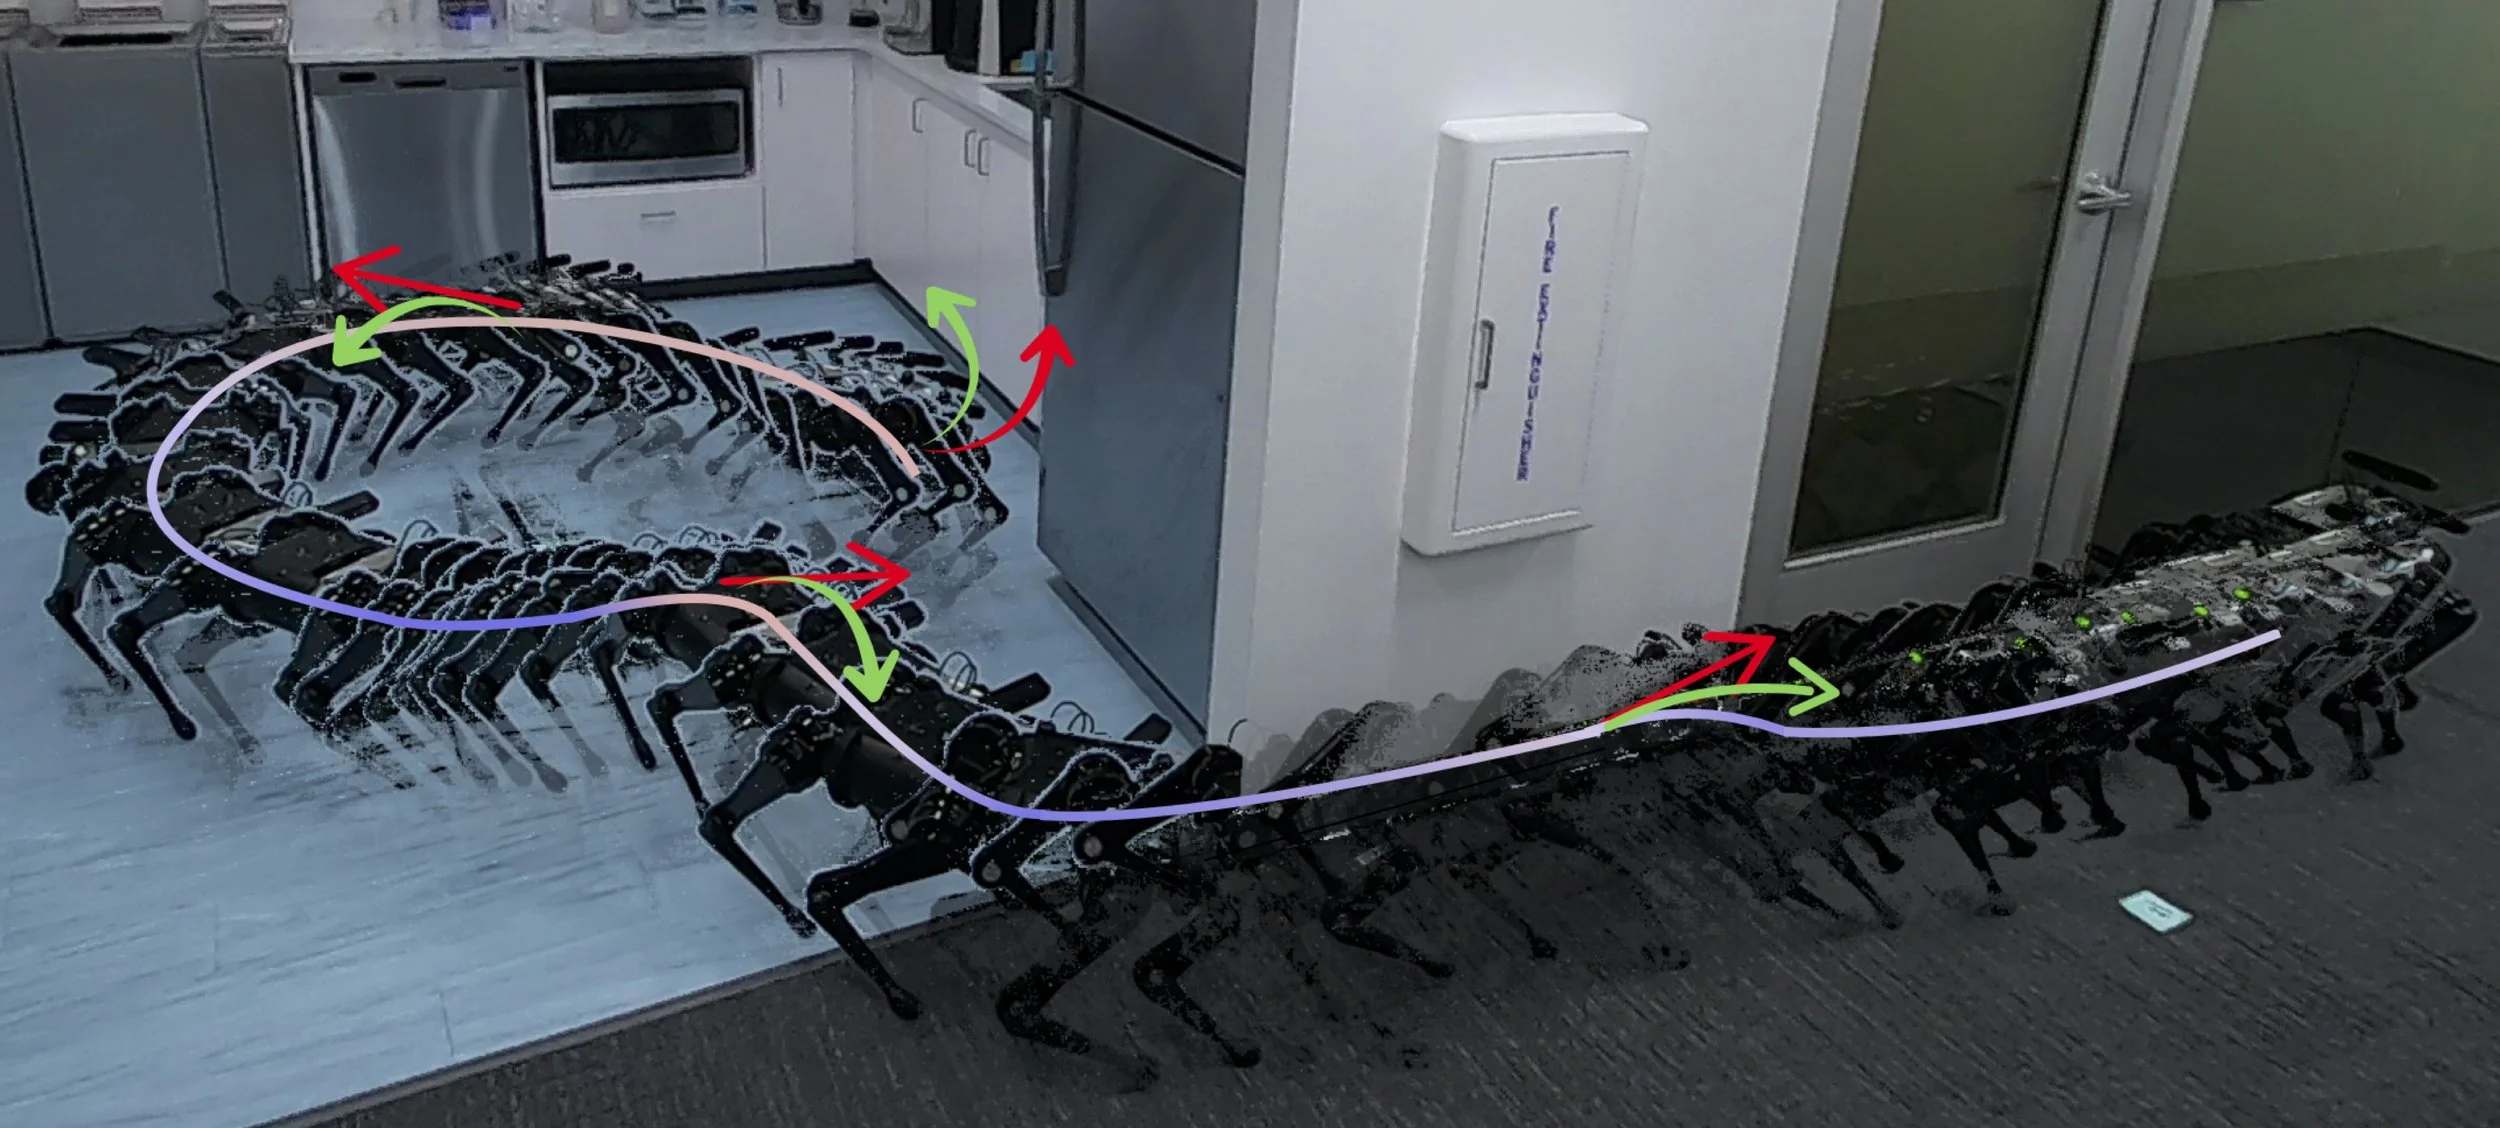
Safety with Agency: Human-Centered Safety Filter with Application to AI-Assisted Motorsports

Robotics: Science and Systems (RSS), 2025
[paper] [homepage] [video] [talk]

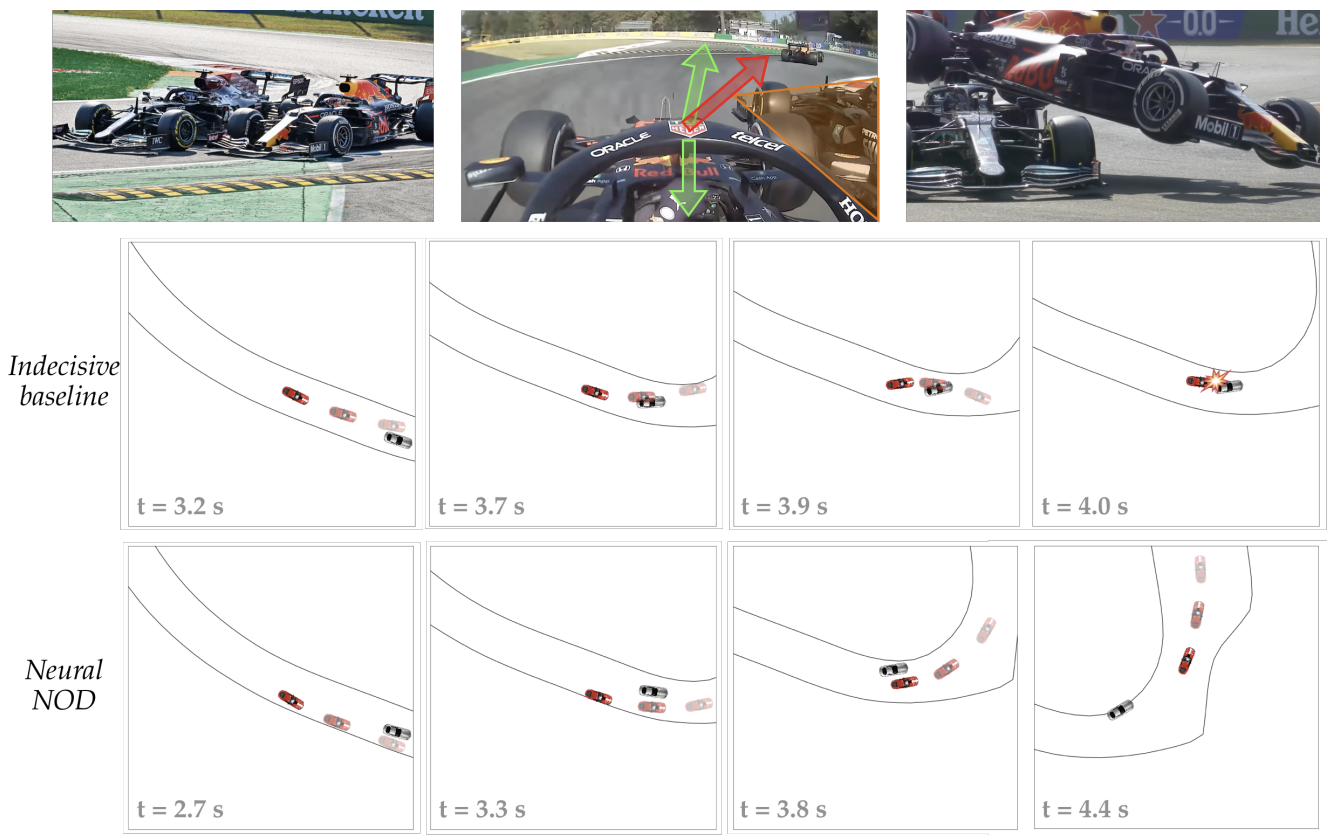
Haimin Hu, Jaime Fernández Fisac, Naomi Ehrich Leonard, Deepak Gopinath, Jonathan DeCastro, Guy Rosman

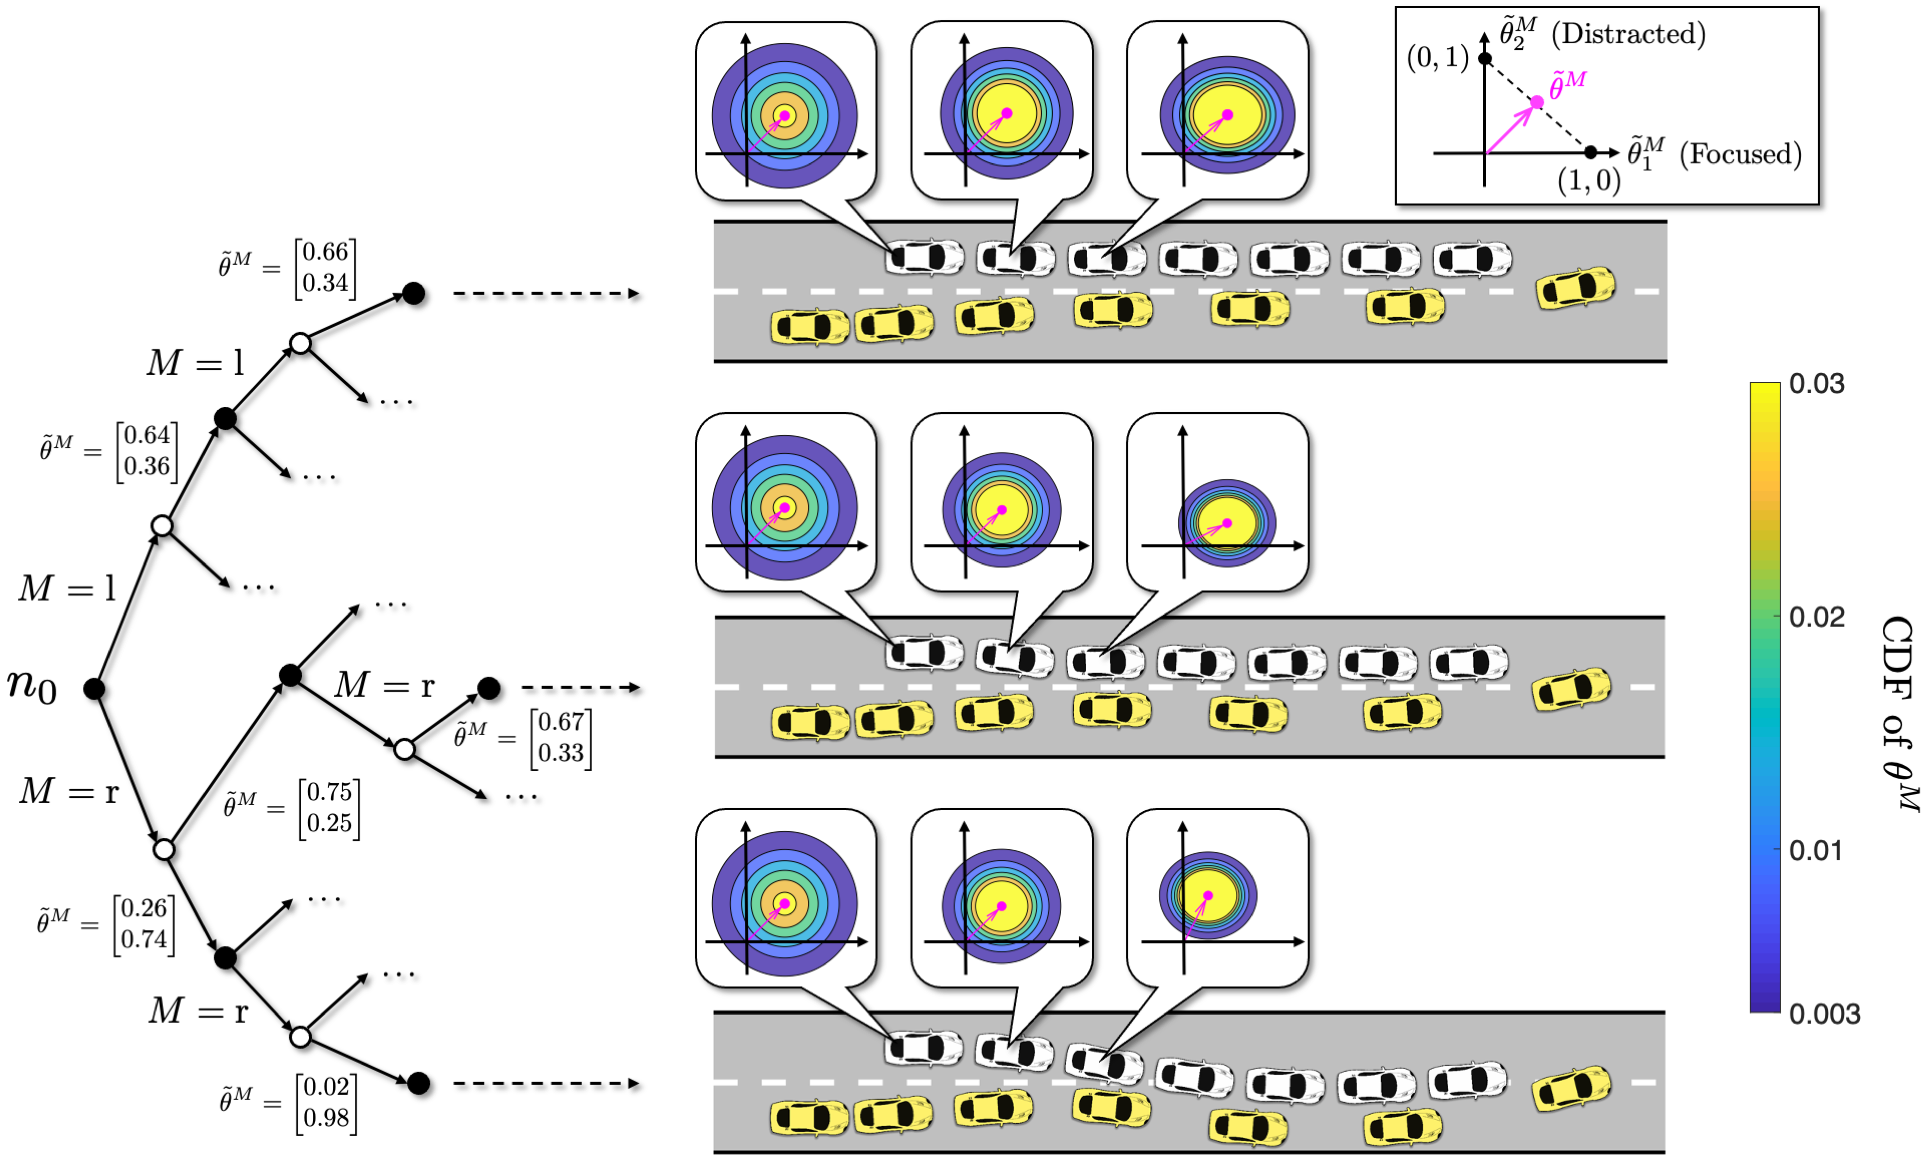
Think Deep and Fast: Learning Neural Nonlinear Opinion Dynamics from Inverse Dynamic Games for Split-Second Interactions

IEEE International Conference on Robotics and Automation (ICRA), 2025

[paper] [poster]

Kaiqu Liang, Zixu Zhang, Jaime F. Fisac

Introspective Planning: Aligning Robots' Uncertainty with Inherent Task Ambiguity

Neural Information Processing Systems (NeurIPS), 2024

[paper] [code] [homepage]

Justin Wang, Haimin Hu, Duy P. Nguyen, Jaime F. Fisac

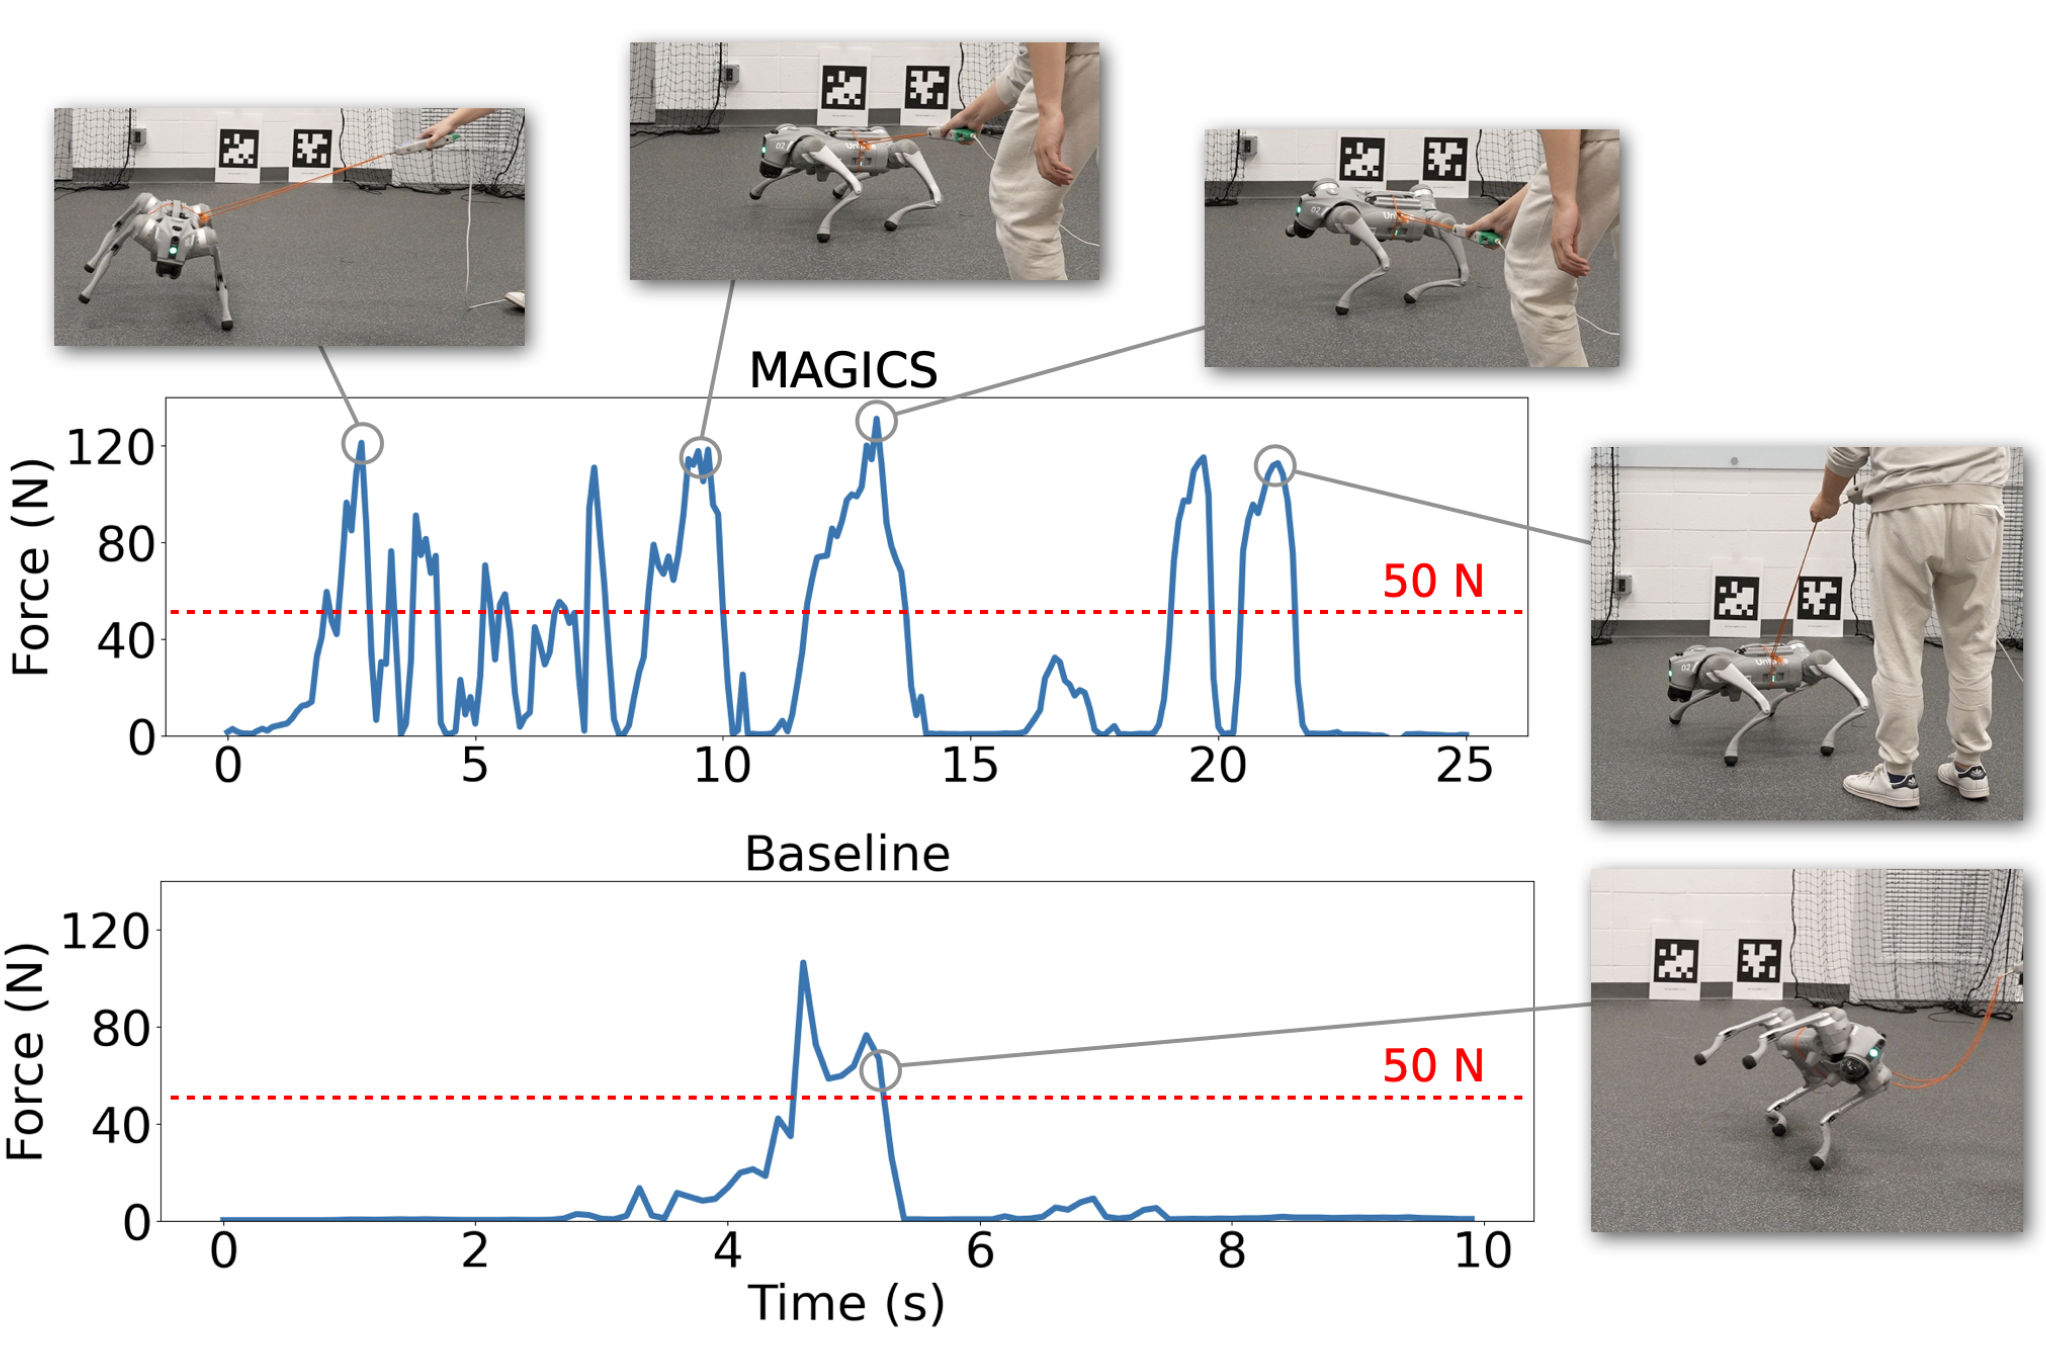
MAGICS: Adversarial RL with Minimax Actors Guided by Implicit Critic Stackelberg for Convergent Neural Synthesis of Robot Safety

Workshop on the Algorithmic Foundations of Robotics (WAFR), 2024

[paper] [video]

Duy P. Nguyen*, Kai-Chieh Hsu*, Wenhao Yu, Jie Tan, Jaime Fernández Fisac

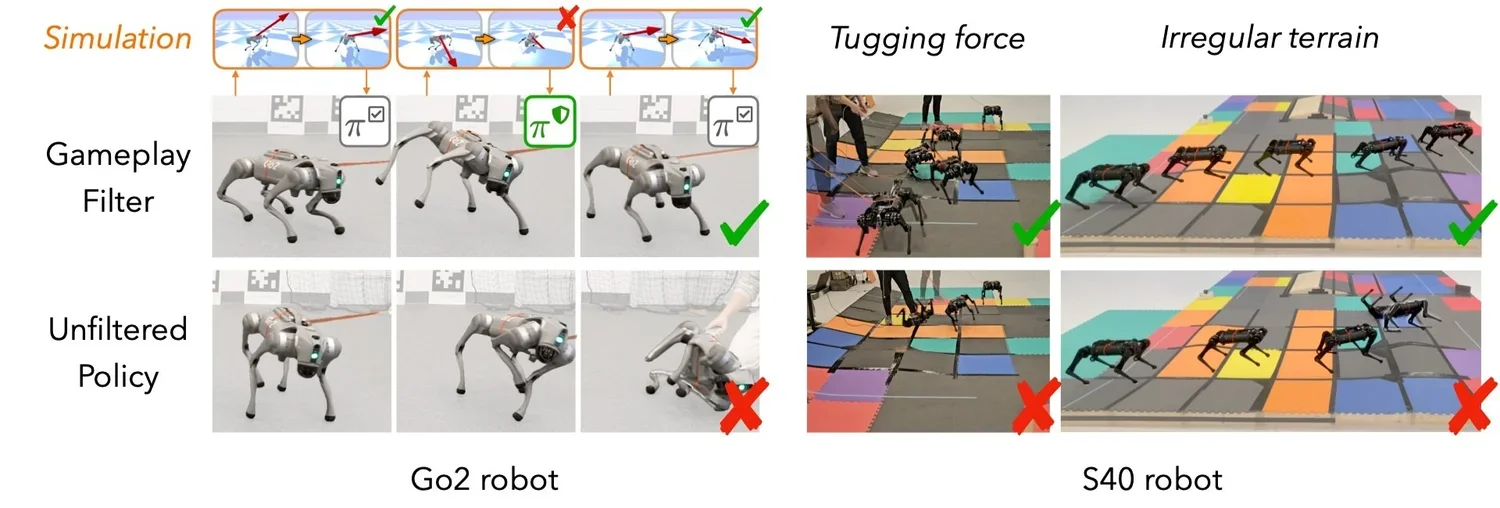
Gameplay Filters: Robust Zero-Shot Safety through Adversarial Imagination

Conference on Robot Learning (CoRL), 2024

[paper] [homepage] [code] [poster]

Haimin Hu*, Gabriele Dragotto*, Zixu Zhang, Kaiqu Liang, Bartolomeo Stellato, Jaime Fernández Fisac

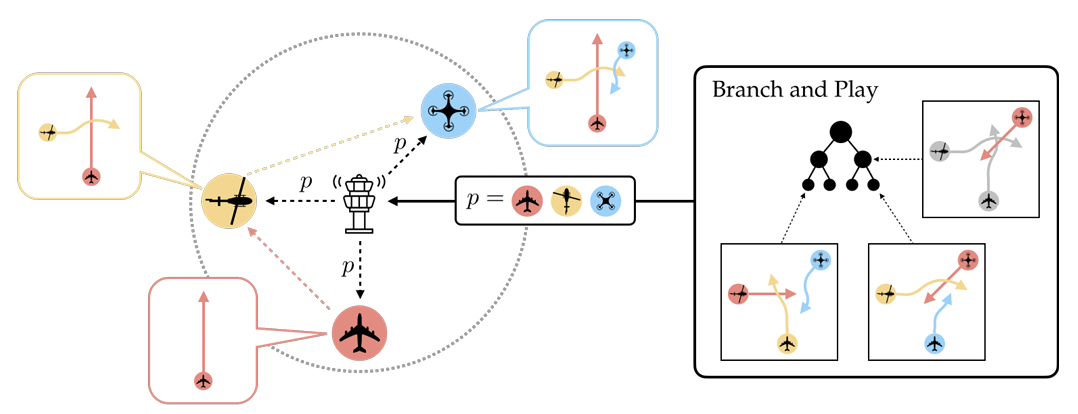
Who Plays First? Optimizing the Order of Play in Stackelberg Games with Many Robots

Robotics: Science and Systems (RSS), 2024

[paper] [homepage] [code]

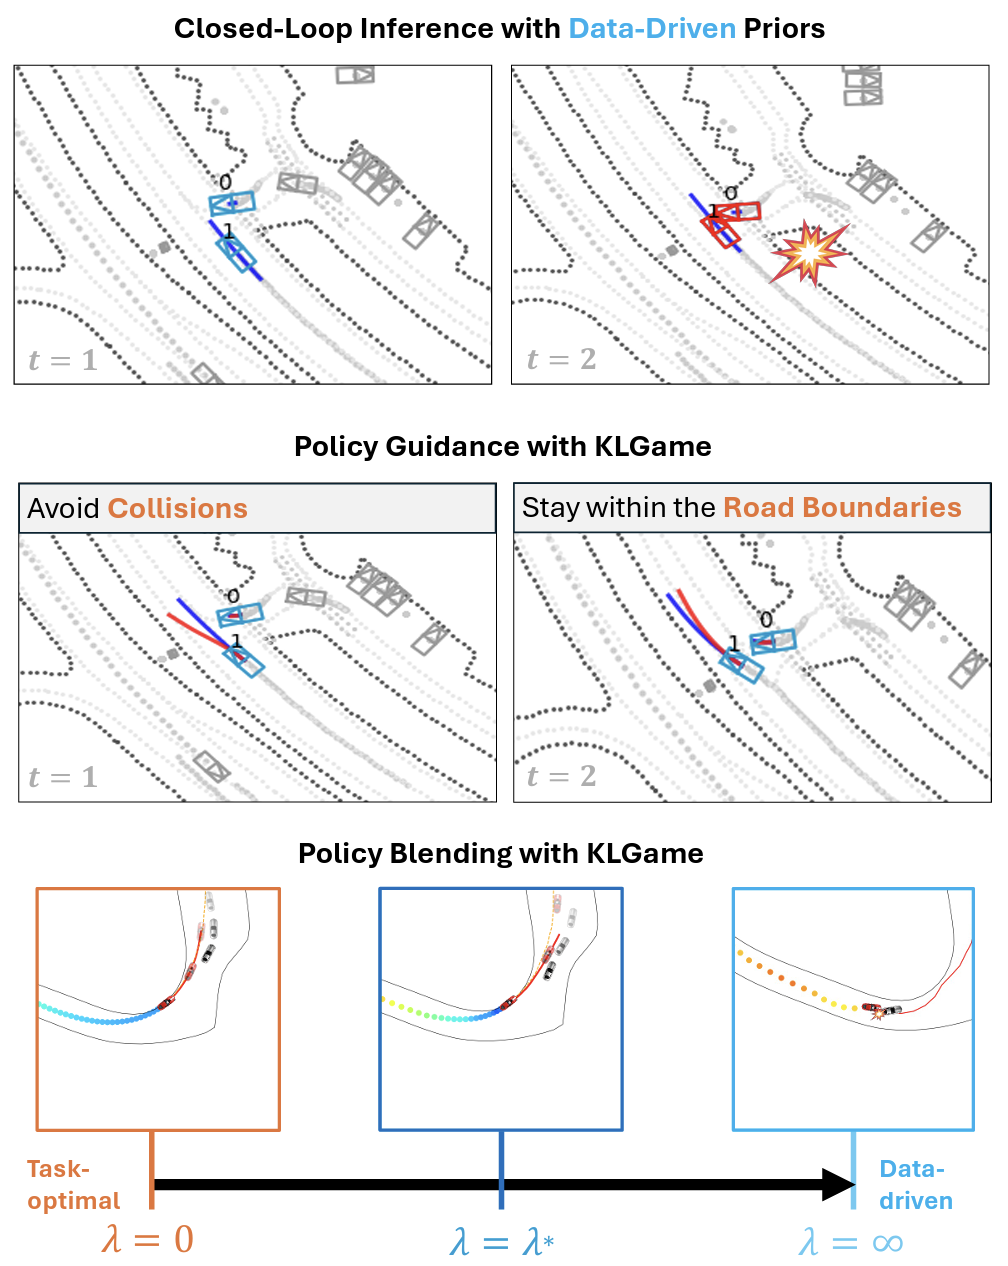
Justin Lidard*, Haimin Hu*, Asher Hancock, Zixu Zhang, Albert Gimó Contreras, Vikash Modi, Jonathan DeCastro, Deepak Gopinath, Guy Rosman, Naomi Ehrich Leonard, María Santos, Jaime Fernández Fisac

Blending Data-Driven Priors in Dynamic Games

Robotics: Science and Systems (RSS), 2024
[paper] [homepage] [code]

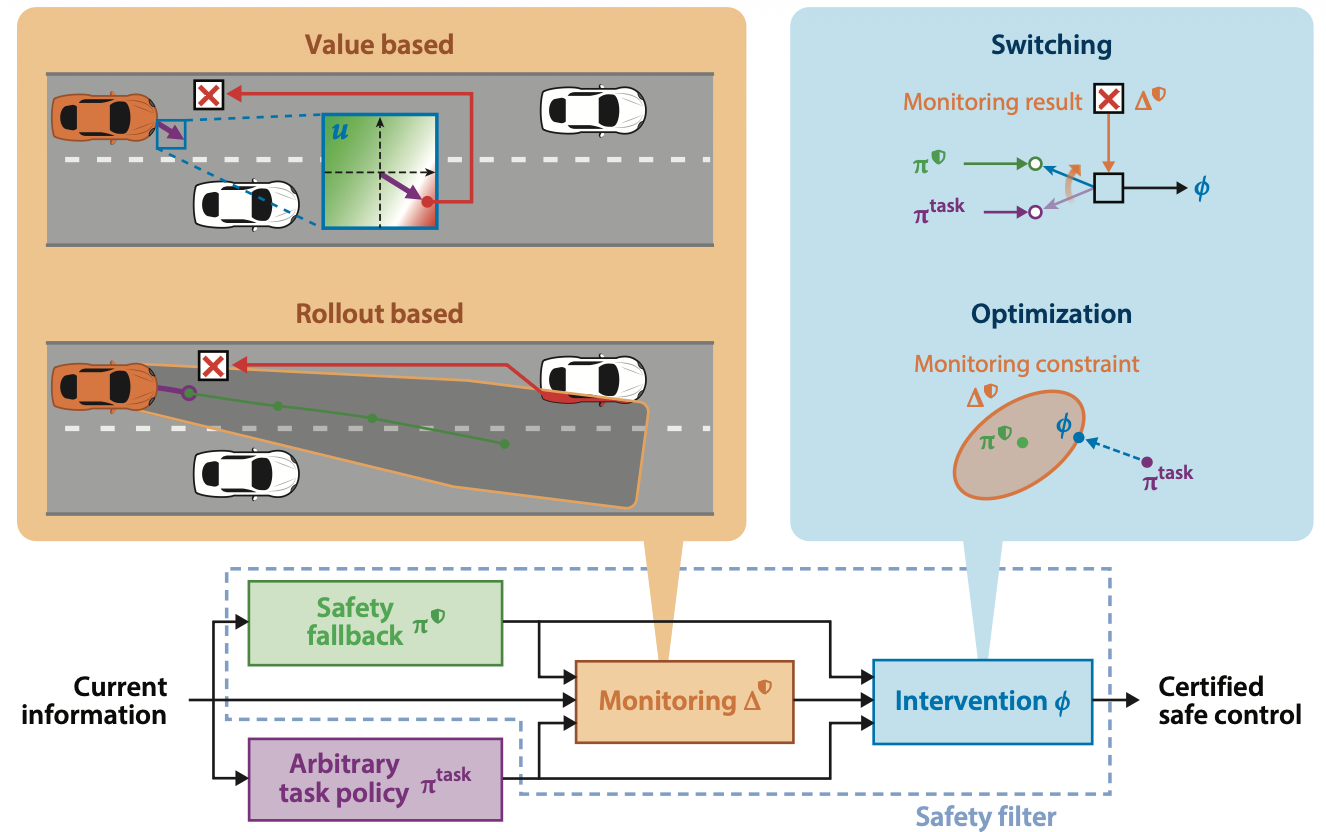
Kai-Chieh Hsu, Haimin Hu, Jaime F. Fisac

The Safety Filter: A Unified View of Safety-Critical Control in Autonomous Systems

Annual Review of Control, Robotics, and Autonomous Systems, 2024

[paper]

Haimin Hu, David Isele, Sangjae Bae, Jaime F. Fisac

Active Uncertainty Reduction for Safe and Efficient Interaction Planning: A Shielding-Aware Dual Control Approach

The International Journal of Robotics Research (IJRR), 2023

[paper] [homepage]

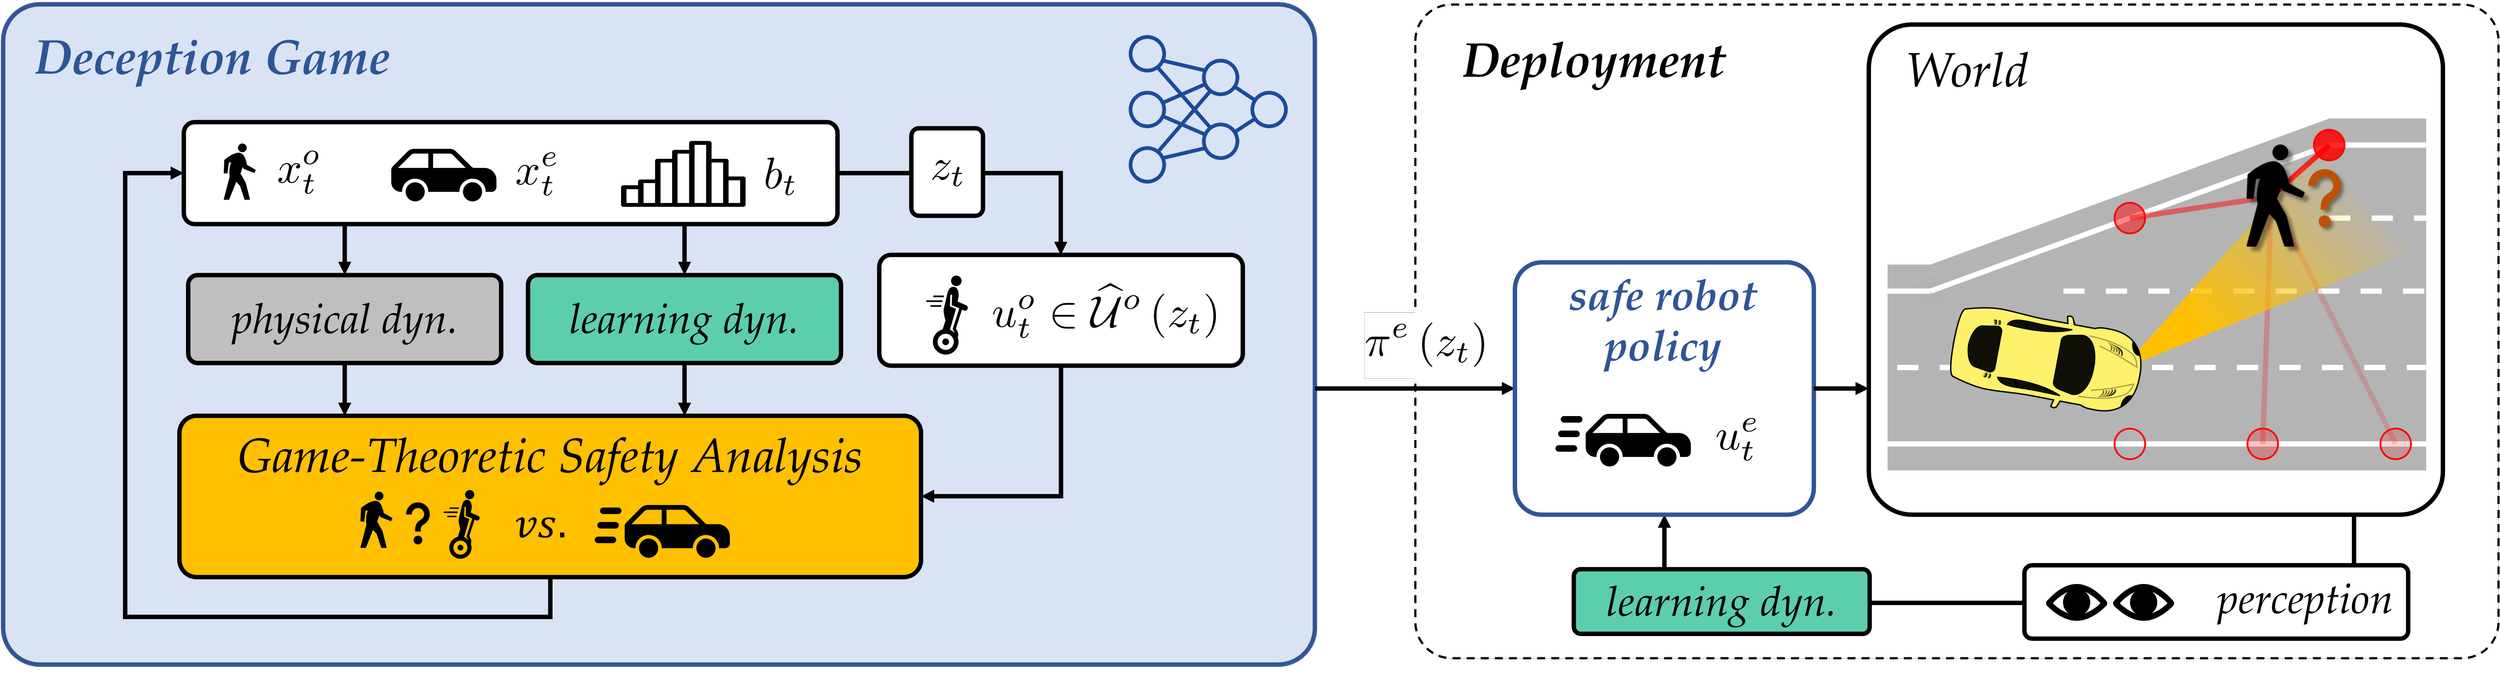
Haimin Hu*, Zixu Zhang*, Kensuke Nakamura, Andrea Bajcsy, and Jaime F. Fisac

Deception Game: Closing the Safety-Learning Loop in Interactive Robot Autonomy

Conference on Robot Learning (CoRL), 2023

[paper] [code] [homepage]

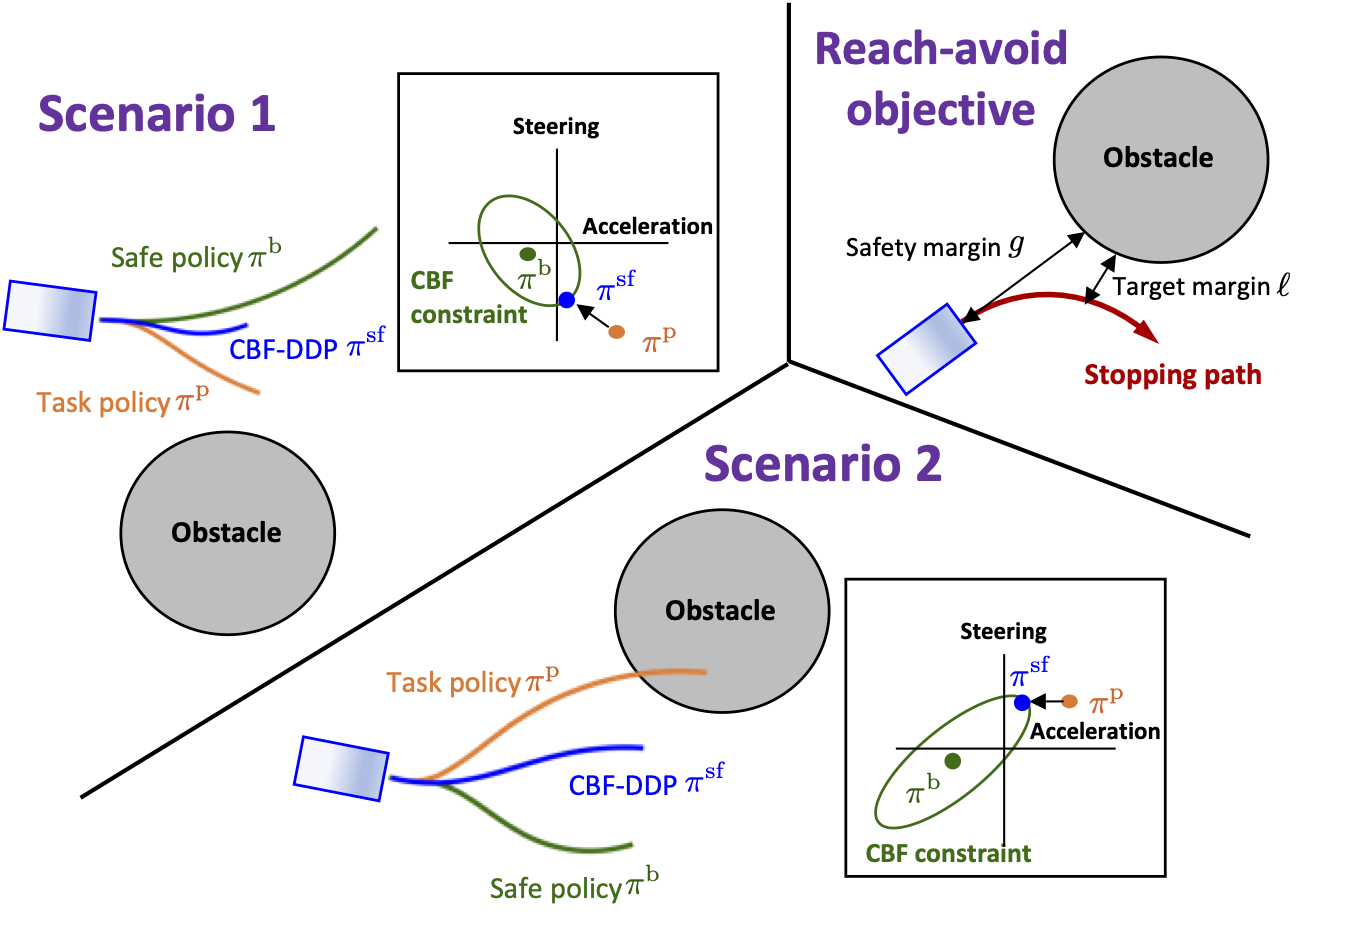
Athindran Ramesh Kumar, Kai-Chieh Hsu, Peter J. Ramadge, and Jaime F. Fisac

Fast, Smooth, and Safe: Implicit Control Barrier Functions Through Reach-Avoid Differential Dynamic Programming

IEEE Control Systems Letters, 2023

[paper] [code] [homepage]

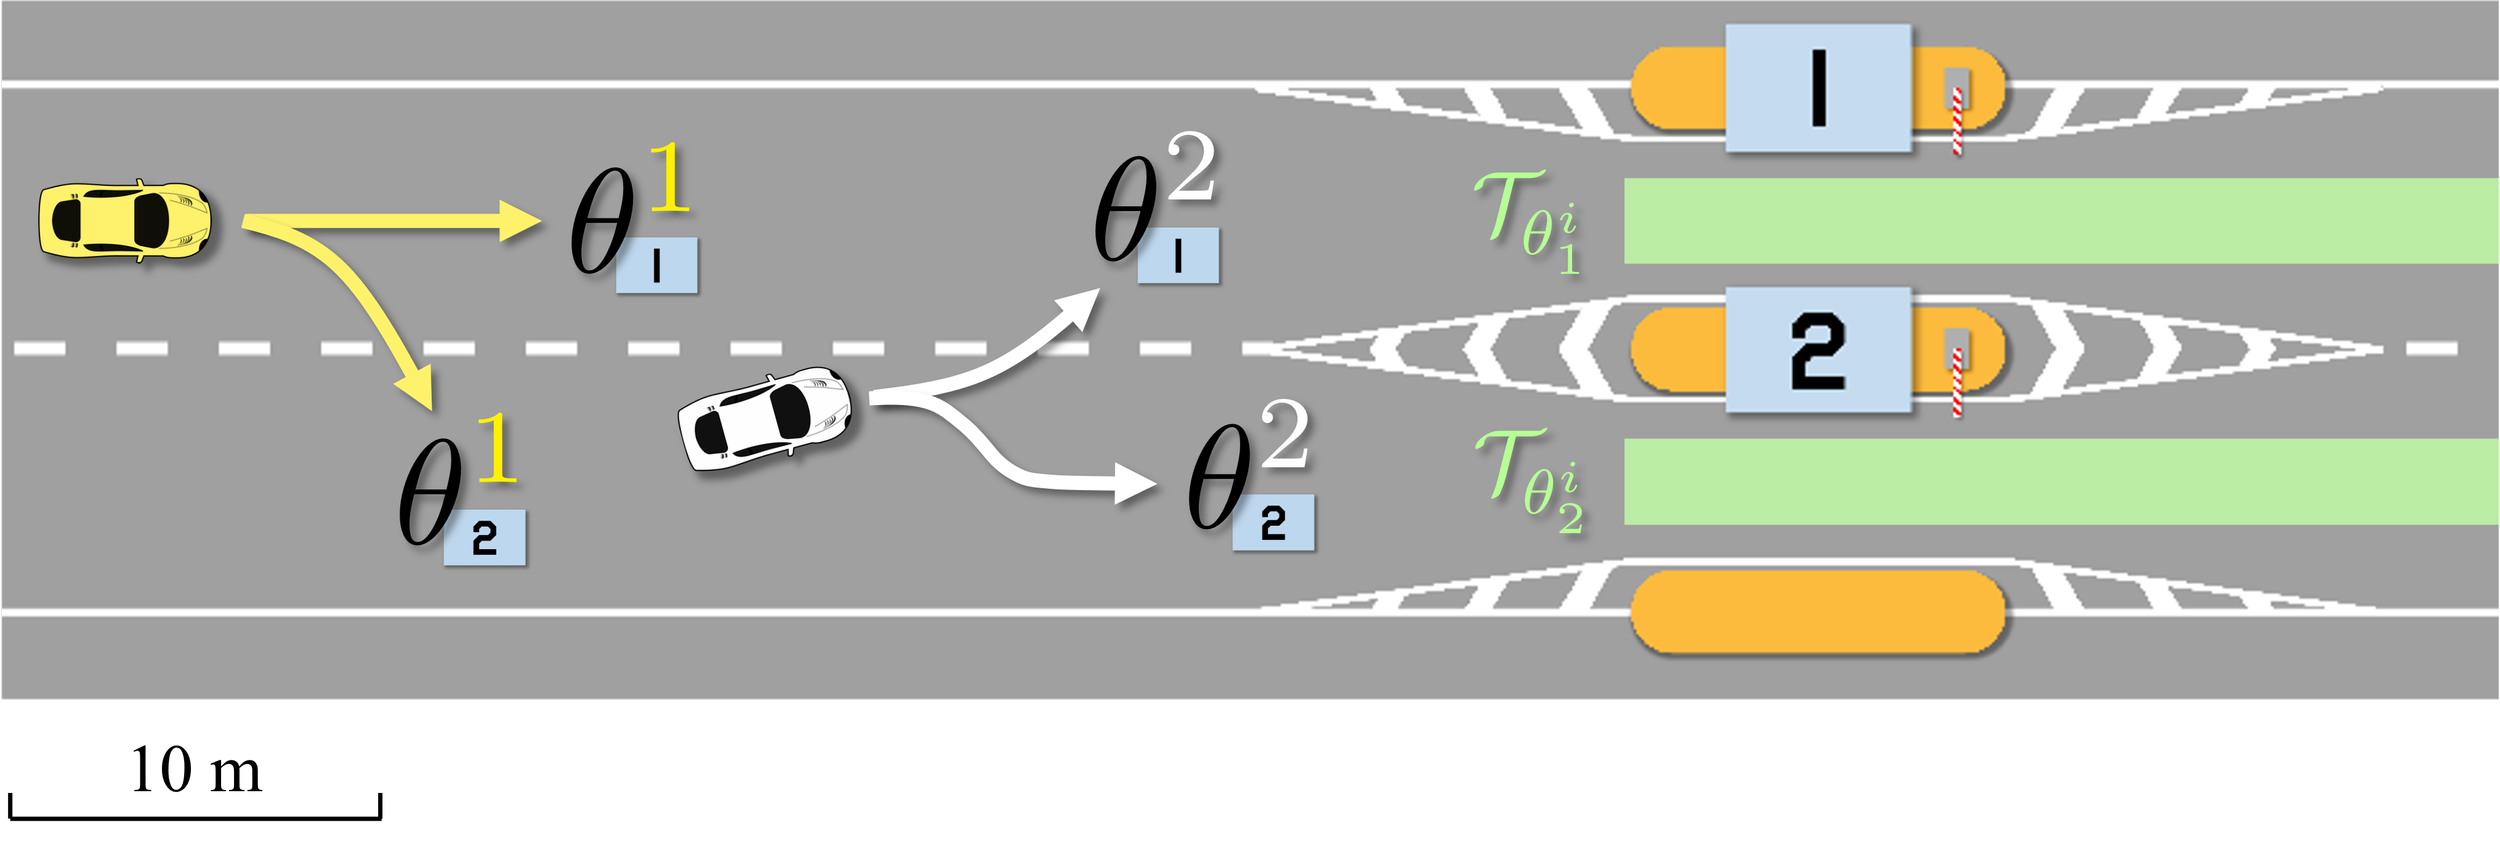
Haimin Hu, Kensuke Nakamura, Kai-Chieh Hsu, Naomi Ehrich Leonard, and Jaime F. Fisac

Emergent Coordination through Game-Induced Nonlinear Opinion Dynamics

IEEE Conference on Decision and Control (CDC), 2023

[paper] [code] [homepage]

Kai-Chieh Hsu, Karen Leung, Yuxiao Chen, Jaime F. Fisac, and Marco Pavone

Interpretable Trajectory Prediction for Autonomous Vehicles via Counterfactual Responsibility

IEEE/RSJ Int. Conf. on Intelligent Robots & Systems, 2023

[paper] [homepage]

Kai-Chieh Hsu, Duy P. Nguyen, and Jaime F. Fisac

ISAACS: Iterative Soft Adversarial Actor Critic for Safety

The 5th Conference on Learning for Dynamics and Control (L4DC), 2023

[paper] [code] [homepage]

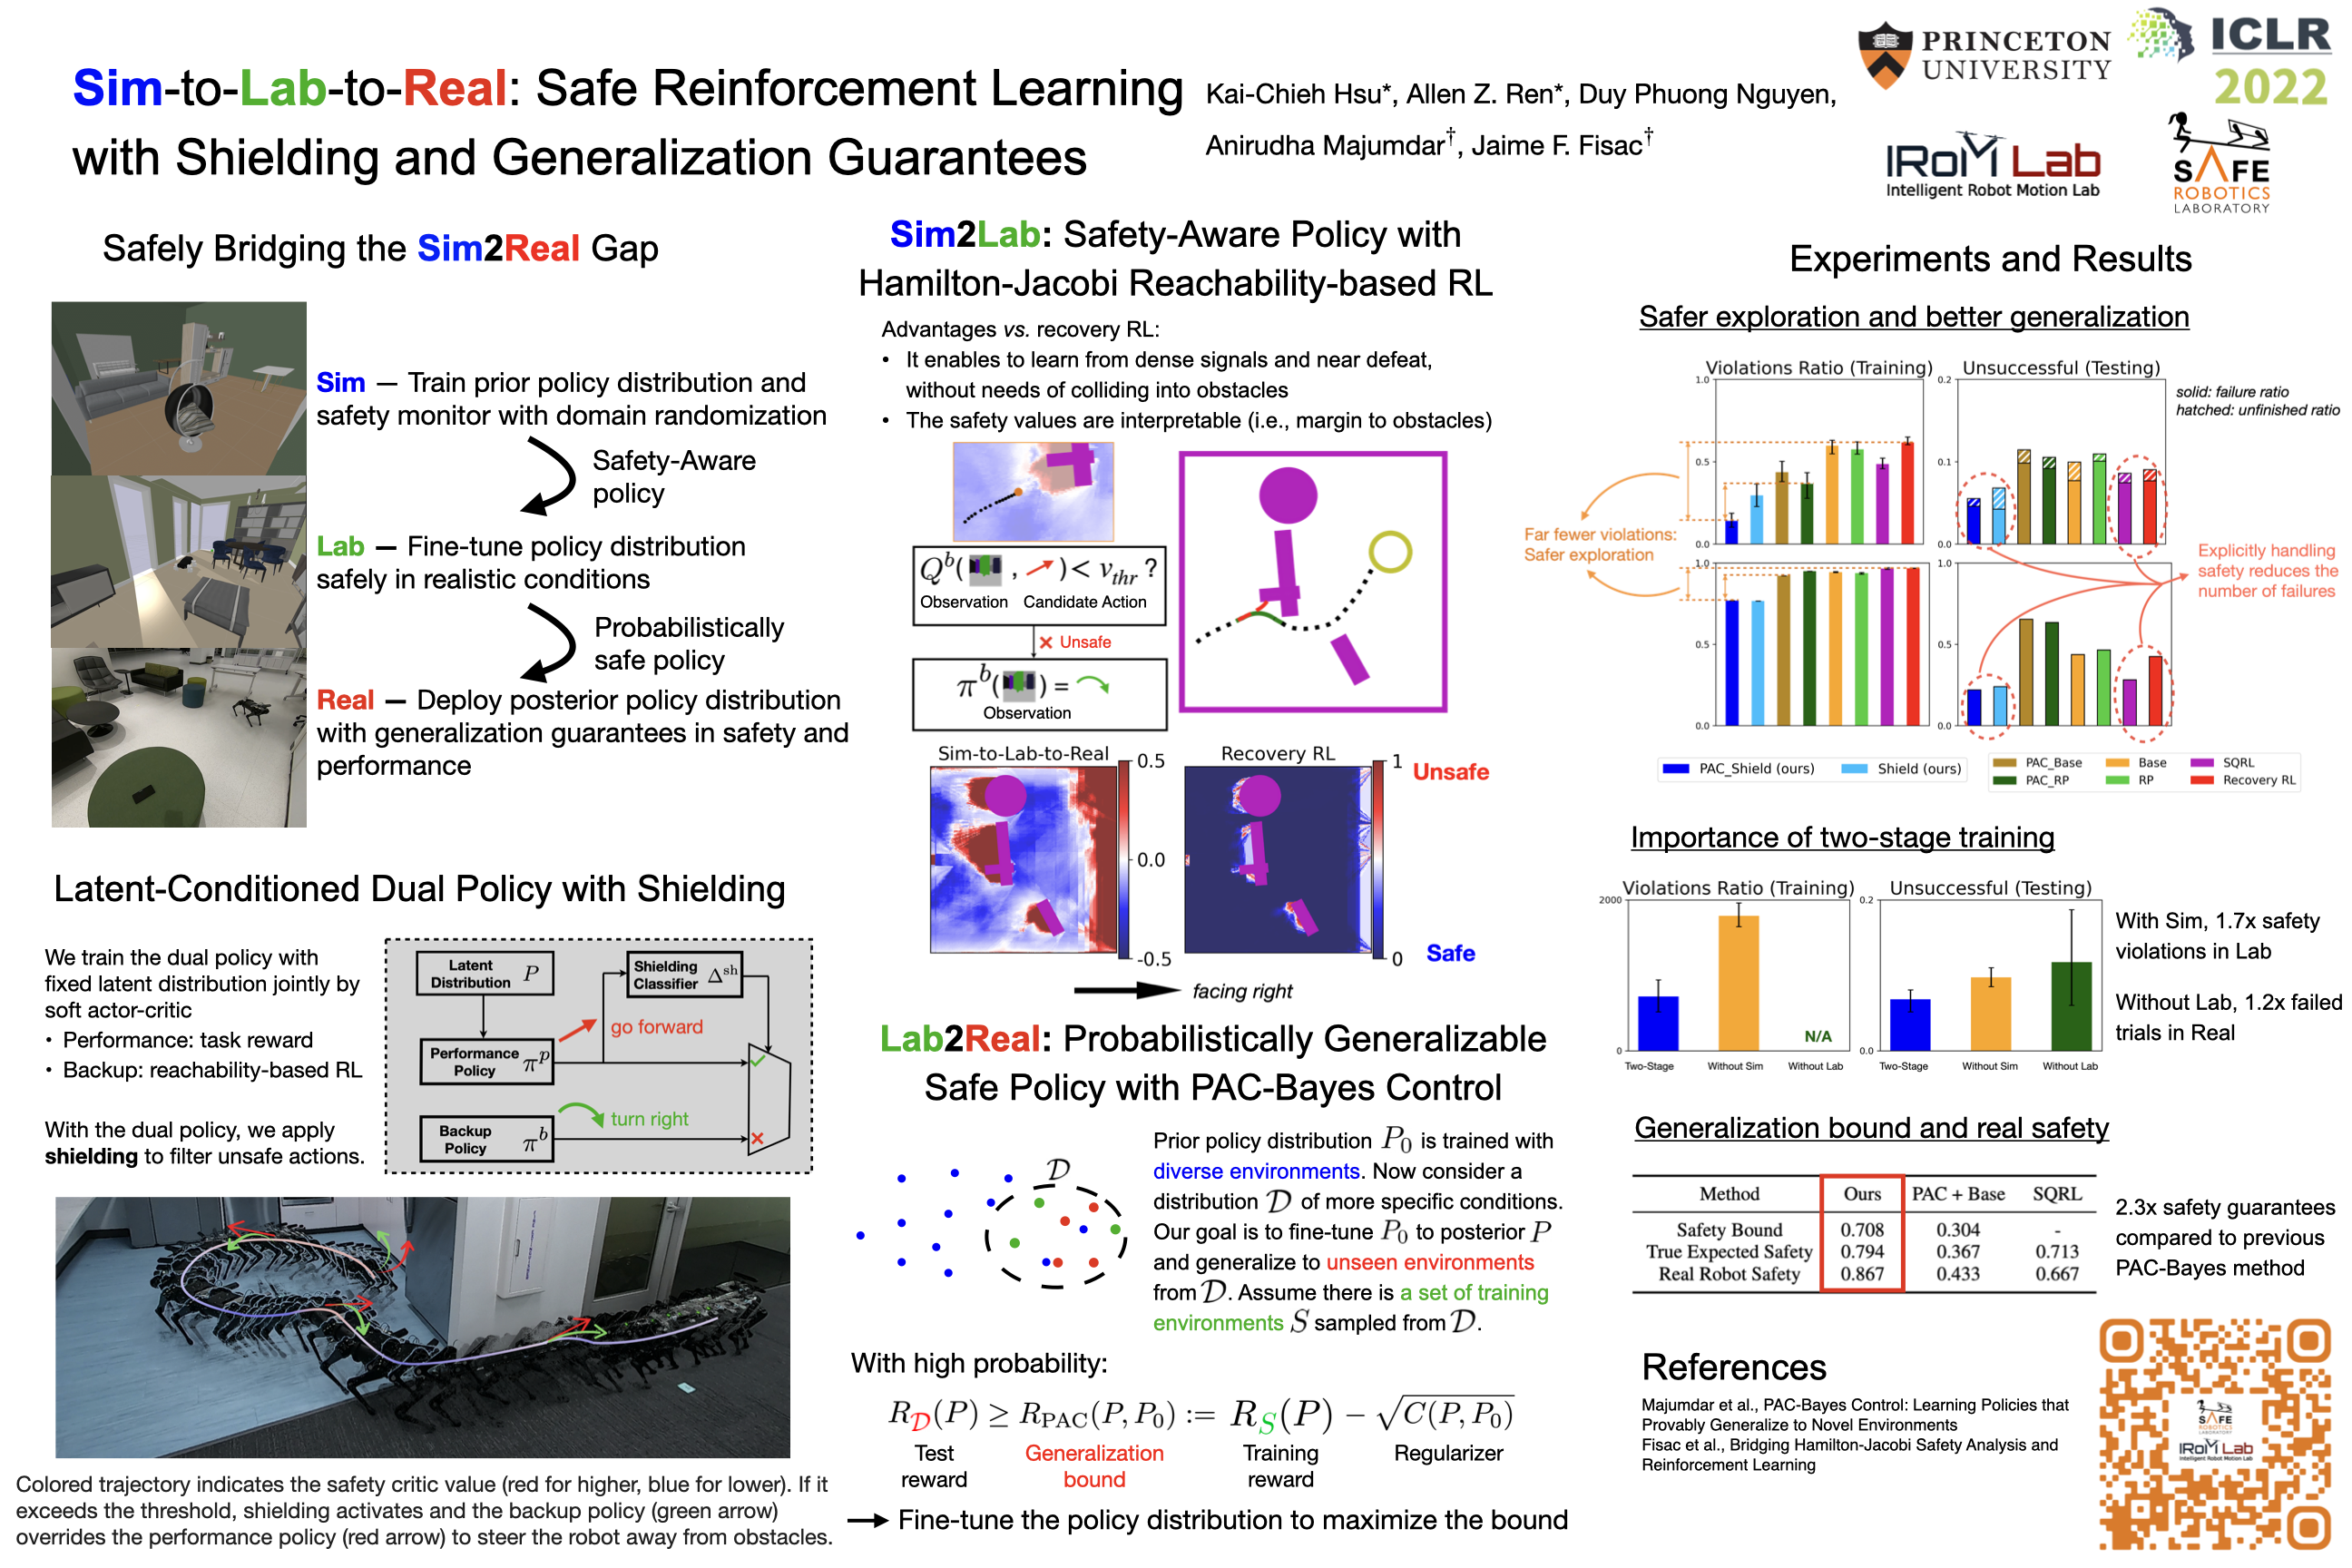
Kai-Chieh Hsu, Allen Z. Ren, Duy P. Nguyen, Anirudha Majumdar, and Jaime F. Fisac

Sim-to-Lab-to-Real: Safe Reinforcement Learning with Shielding and Generalization Guarantees

Artificial Intelligence Journal (AIJ), 2022

[paper] [code] [poster] [homepage]

Haimin Hu and Jaime F. Fisac

Active Uncertainty Reduction for Human-Robot Interaction: An Implicit Dual Control Approach

Algorithmic Foundations of Robotics XV (WAFR), 2022.

[paper] [talk] [code] [homepage]

Haimin Hu, Kensuke Nakamura and Jaime F. Fisac

SHARP: Shielding-Aware Robust Planning for Safe and Efficient Human-Robot Interaction

IEEE Robotics and Automation Letters (RA-L), 2022.

[paper] [talk] [code] [poster] [homepage]

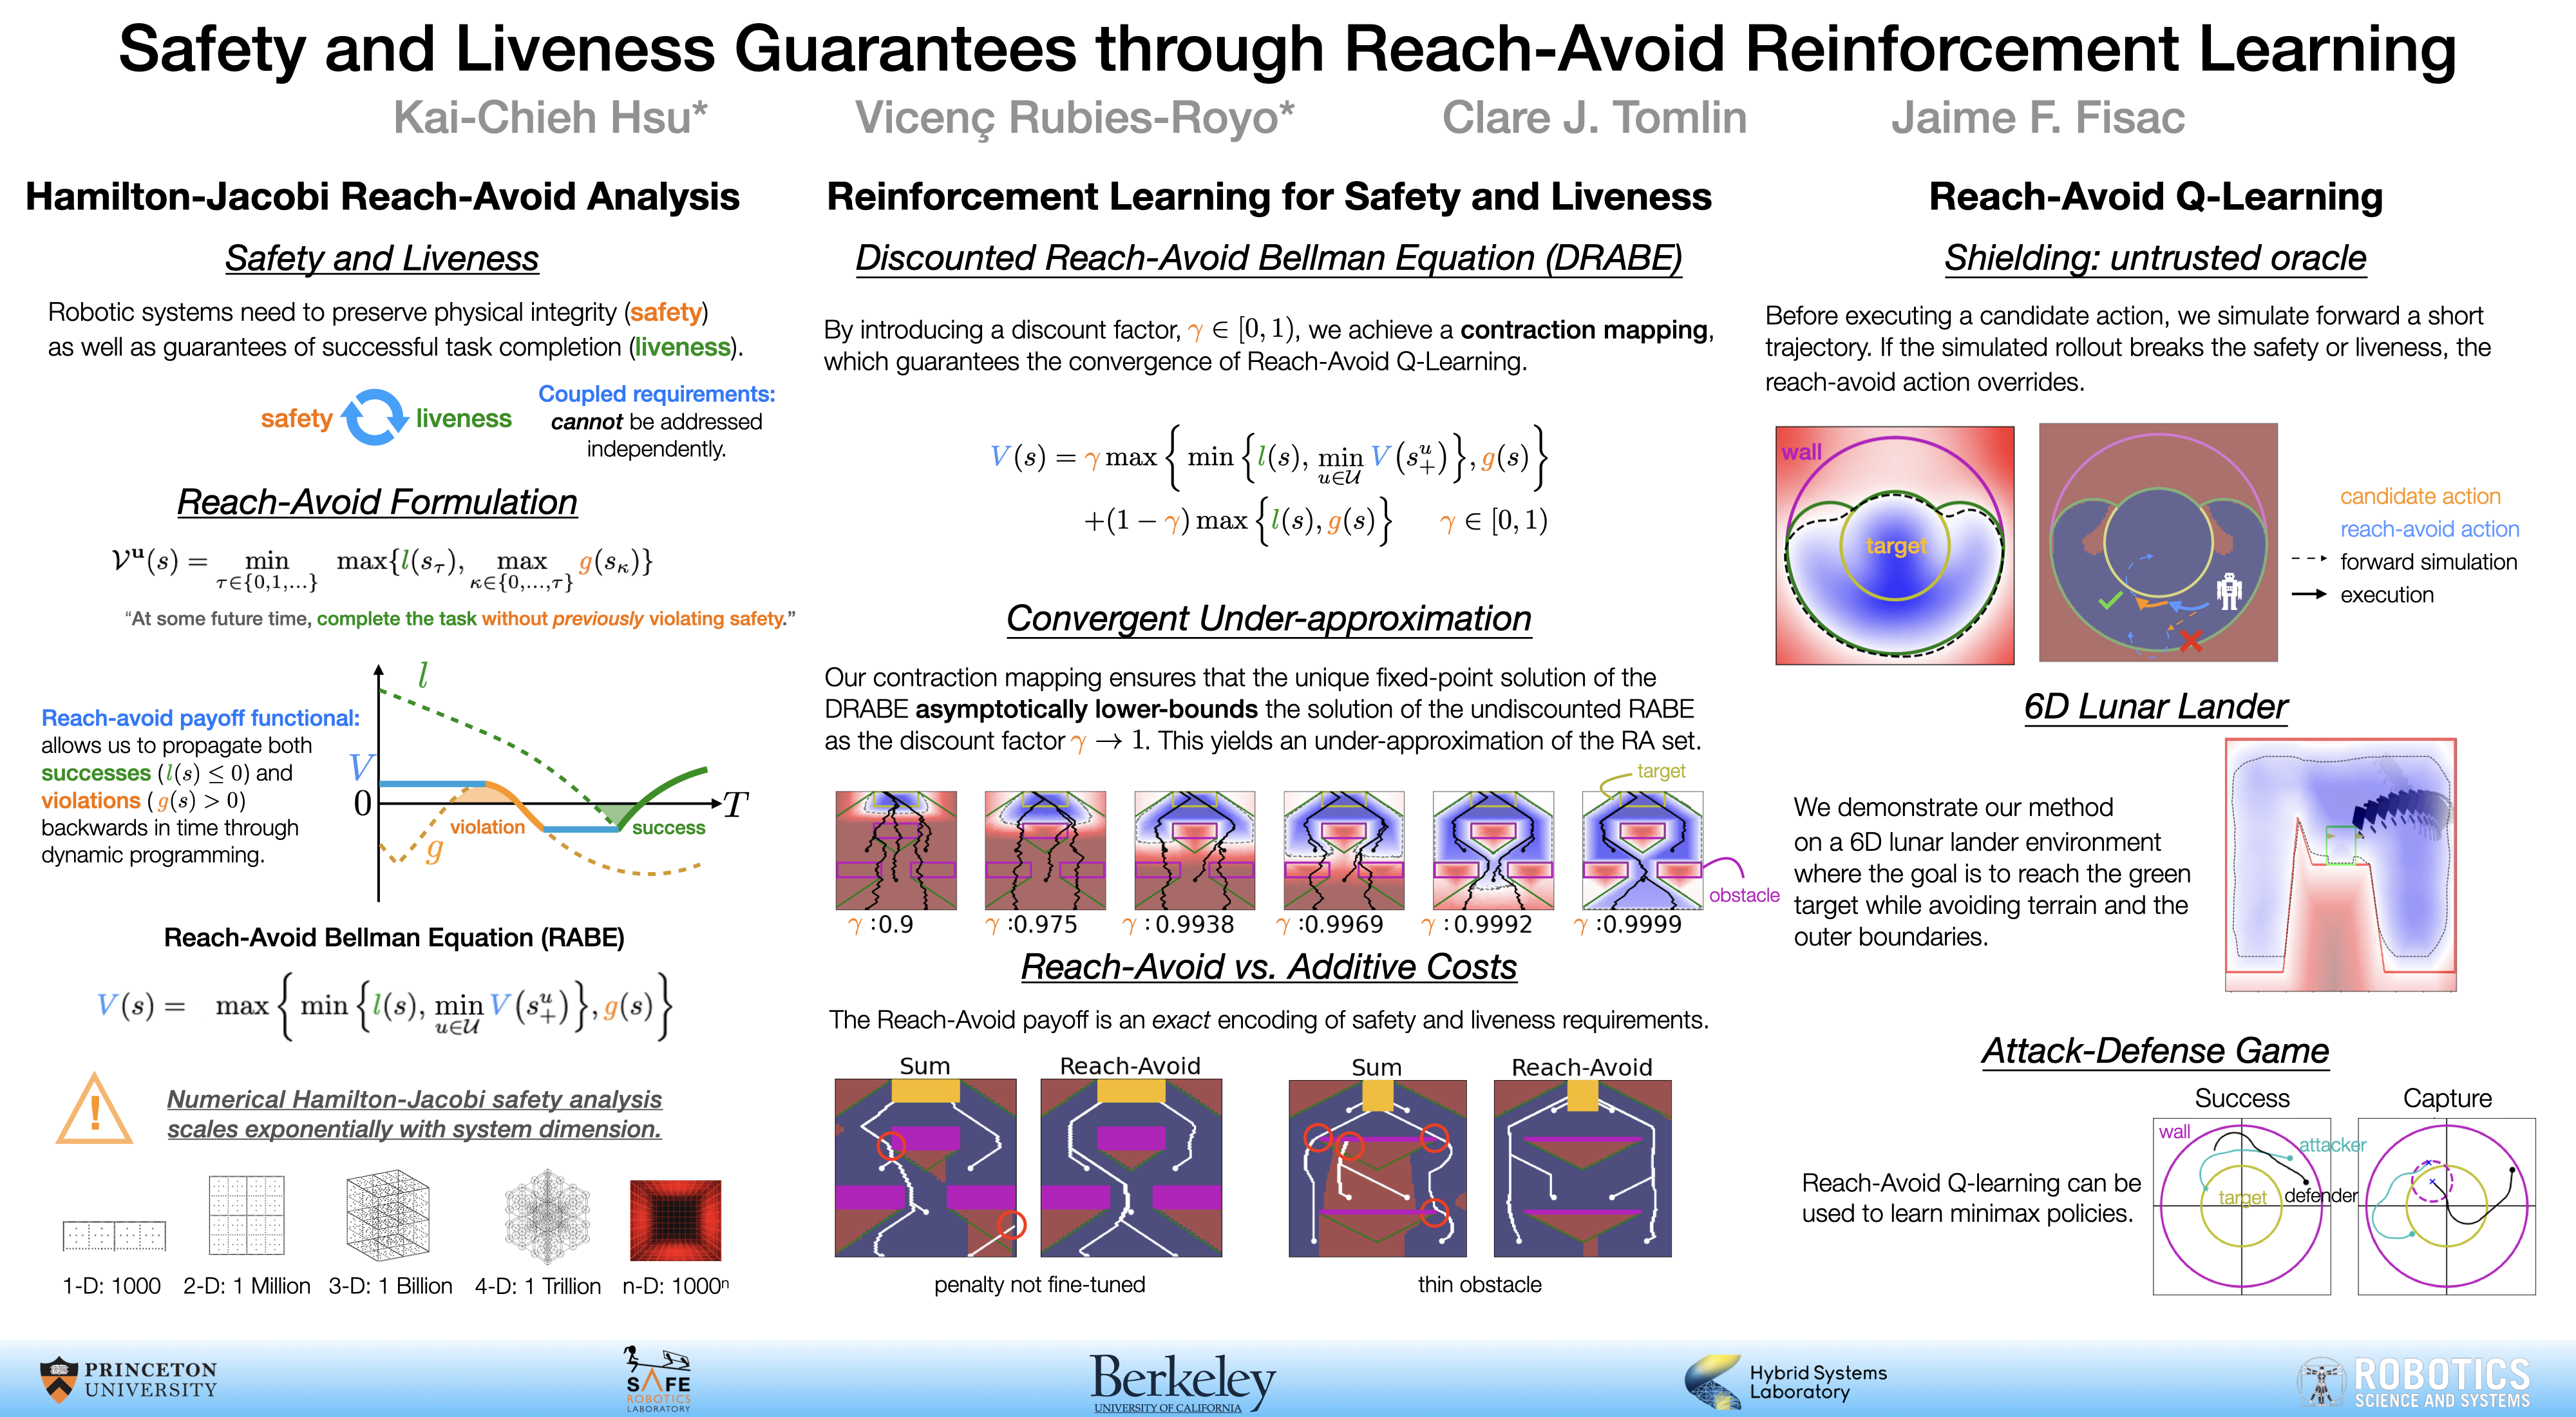
Kai-Chieh Hsu*, Vicenç Rubies-Royo*, Claire J. Tomlin and Jaime F. Fisac

Safety and Liveness Guarantees through Reach-Avoid Reinforcement Learning

Robotics: Science and Systems (RSS), 2021

[paper] [talk] [code] [poster] [homepage]

Zixu Zhang and Jaime F. Fisac

Safe Occlusion-aware Autonomous Driving via Game-Theoretic Active Perception

Robotics: Science and Systems (RSS), 2021

[paper] [talk] [code] [homepage]